PROJECT 01 · 스마트 분리수거 자동화 시스템PROJECT 01 · Smart Recycling Automation System
주요 작업 · 전원 분배 설계·부하 시험·STM32 모터 제어
Featured case · Power distribution and motor drive integration in an automated system
자동 분류부터 세척까지 연결한 분리수거 장비
Built an automated recycling, sorting and cleaning prototype
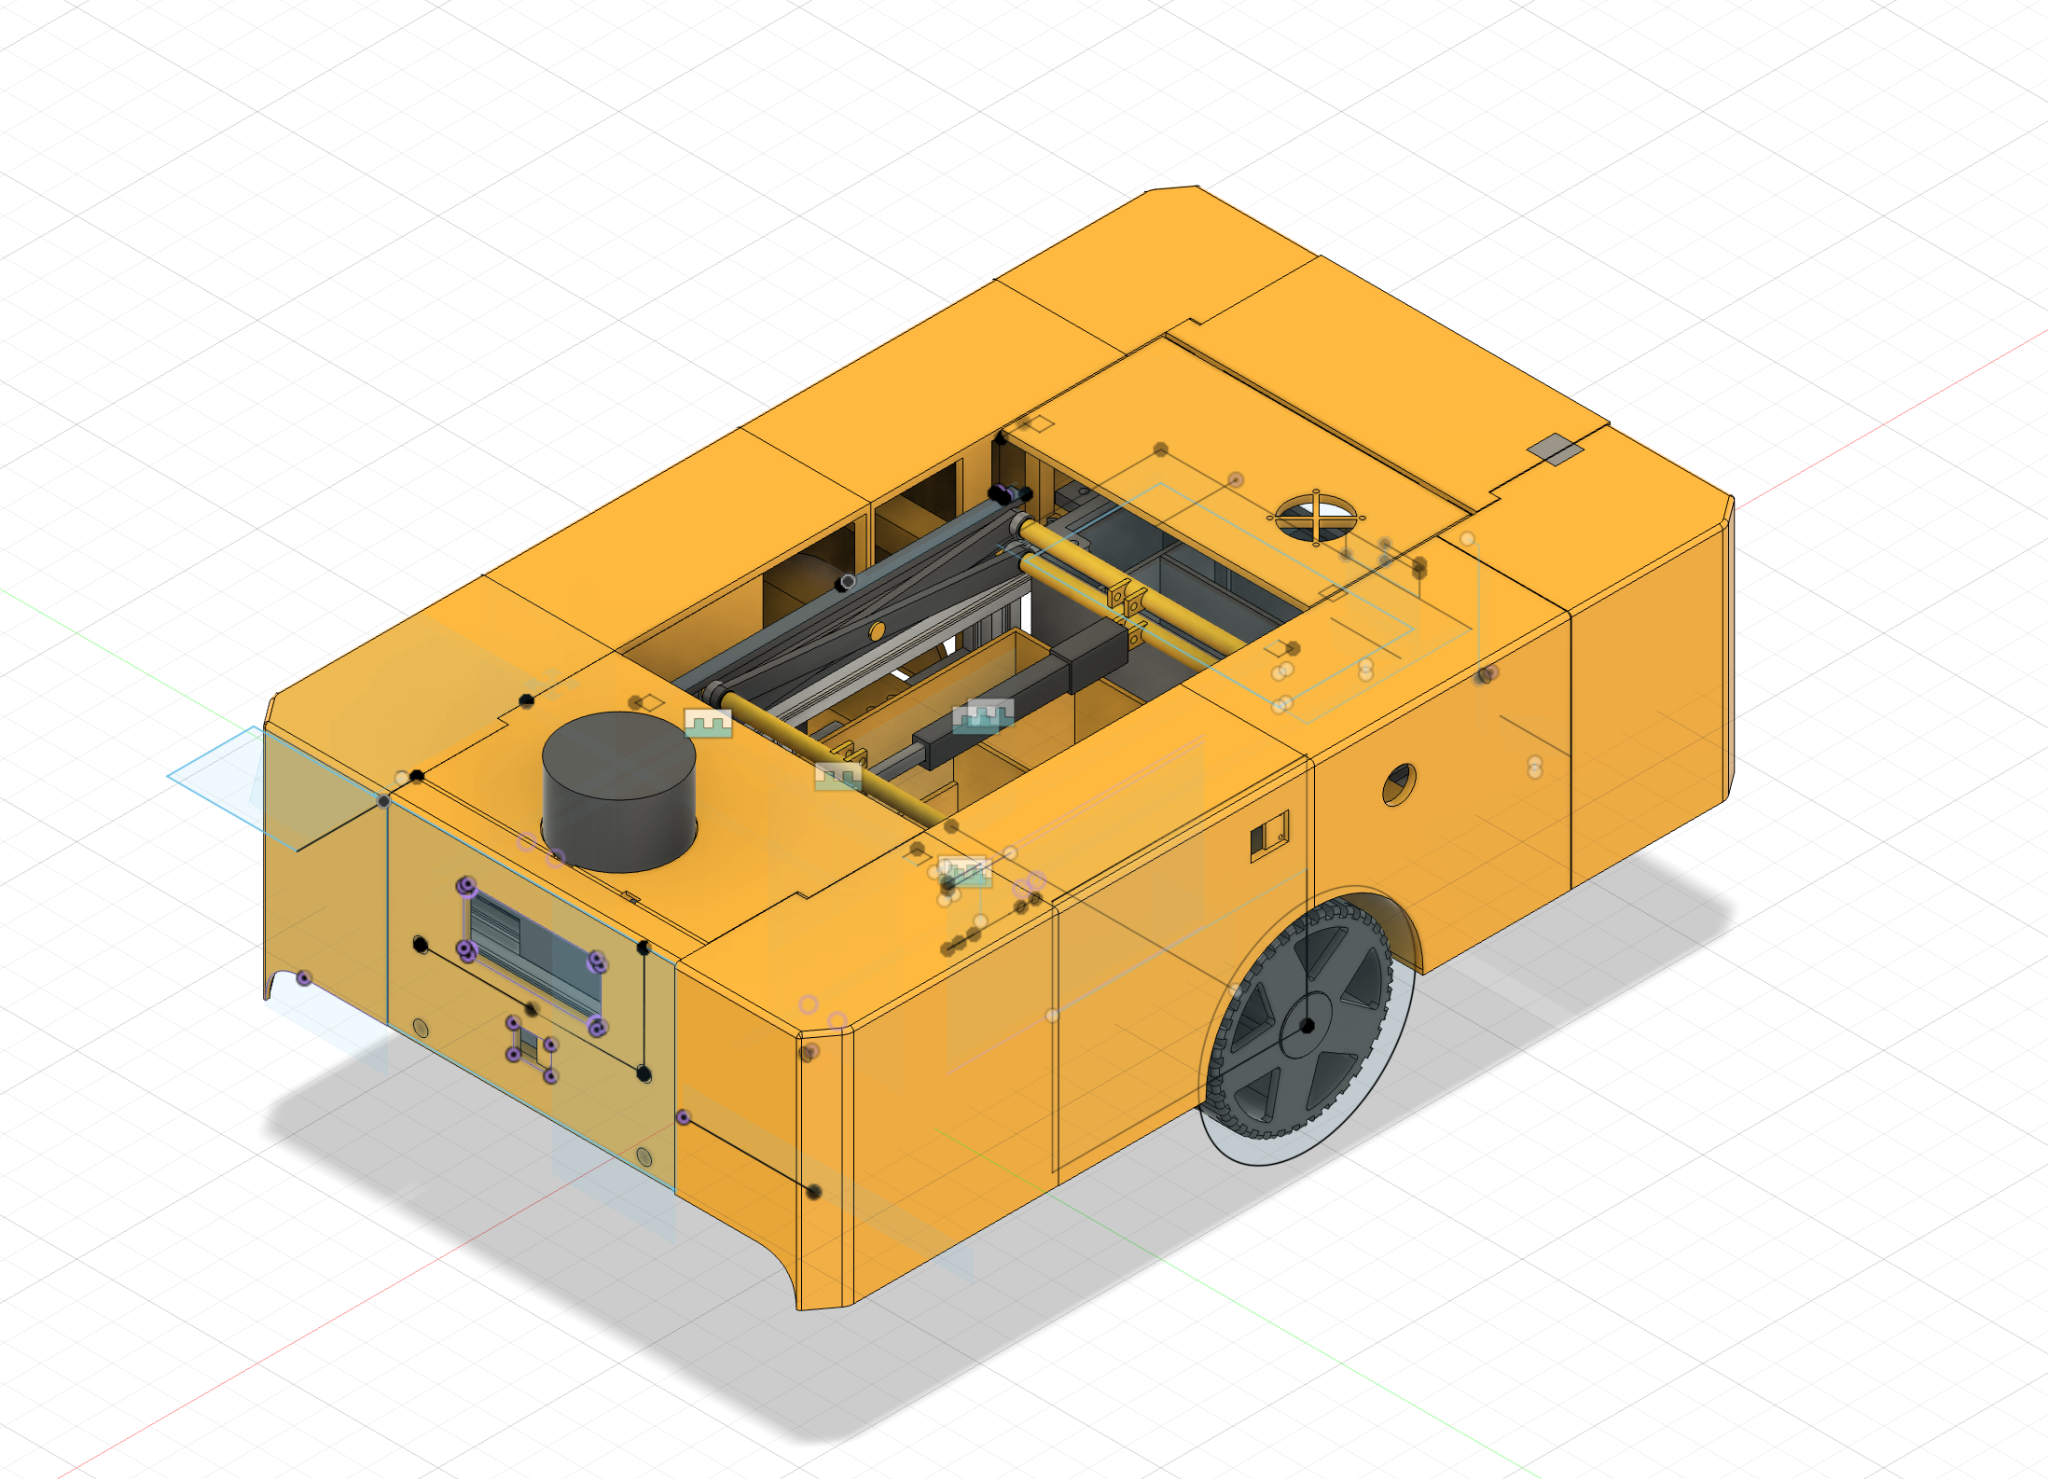
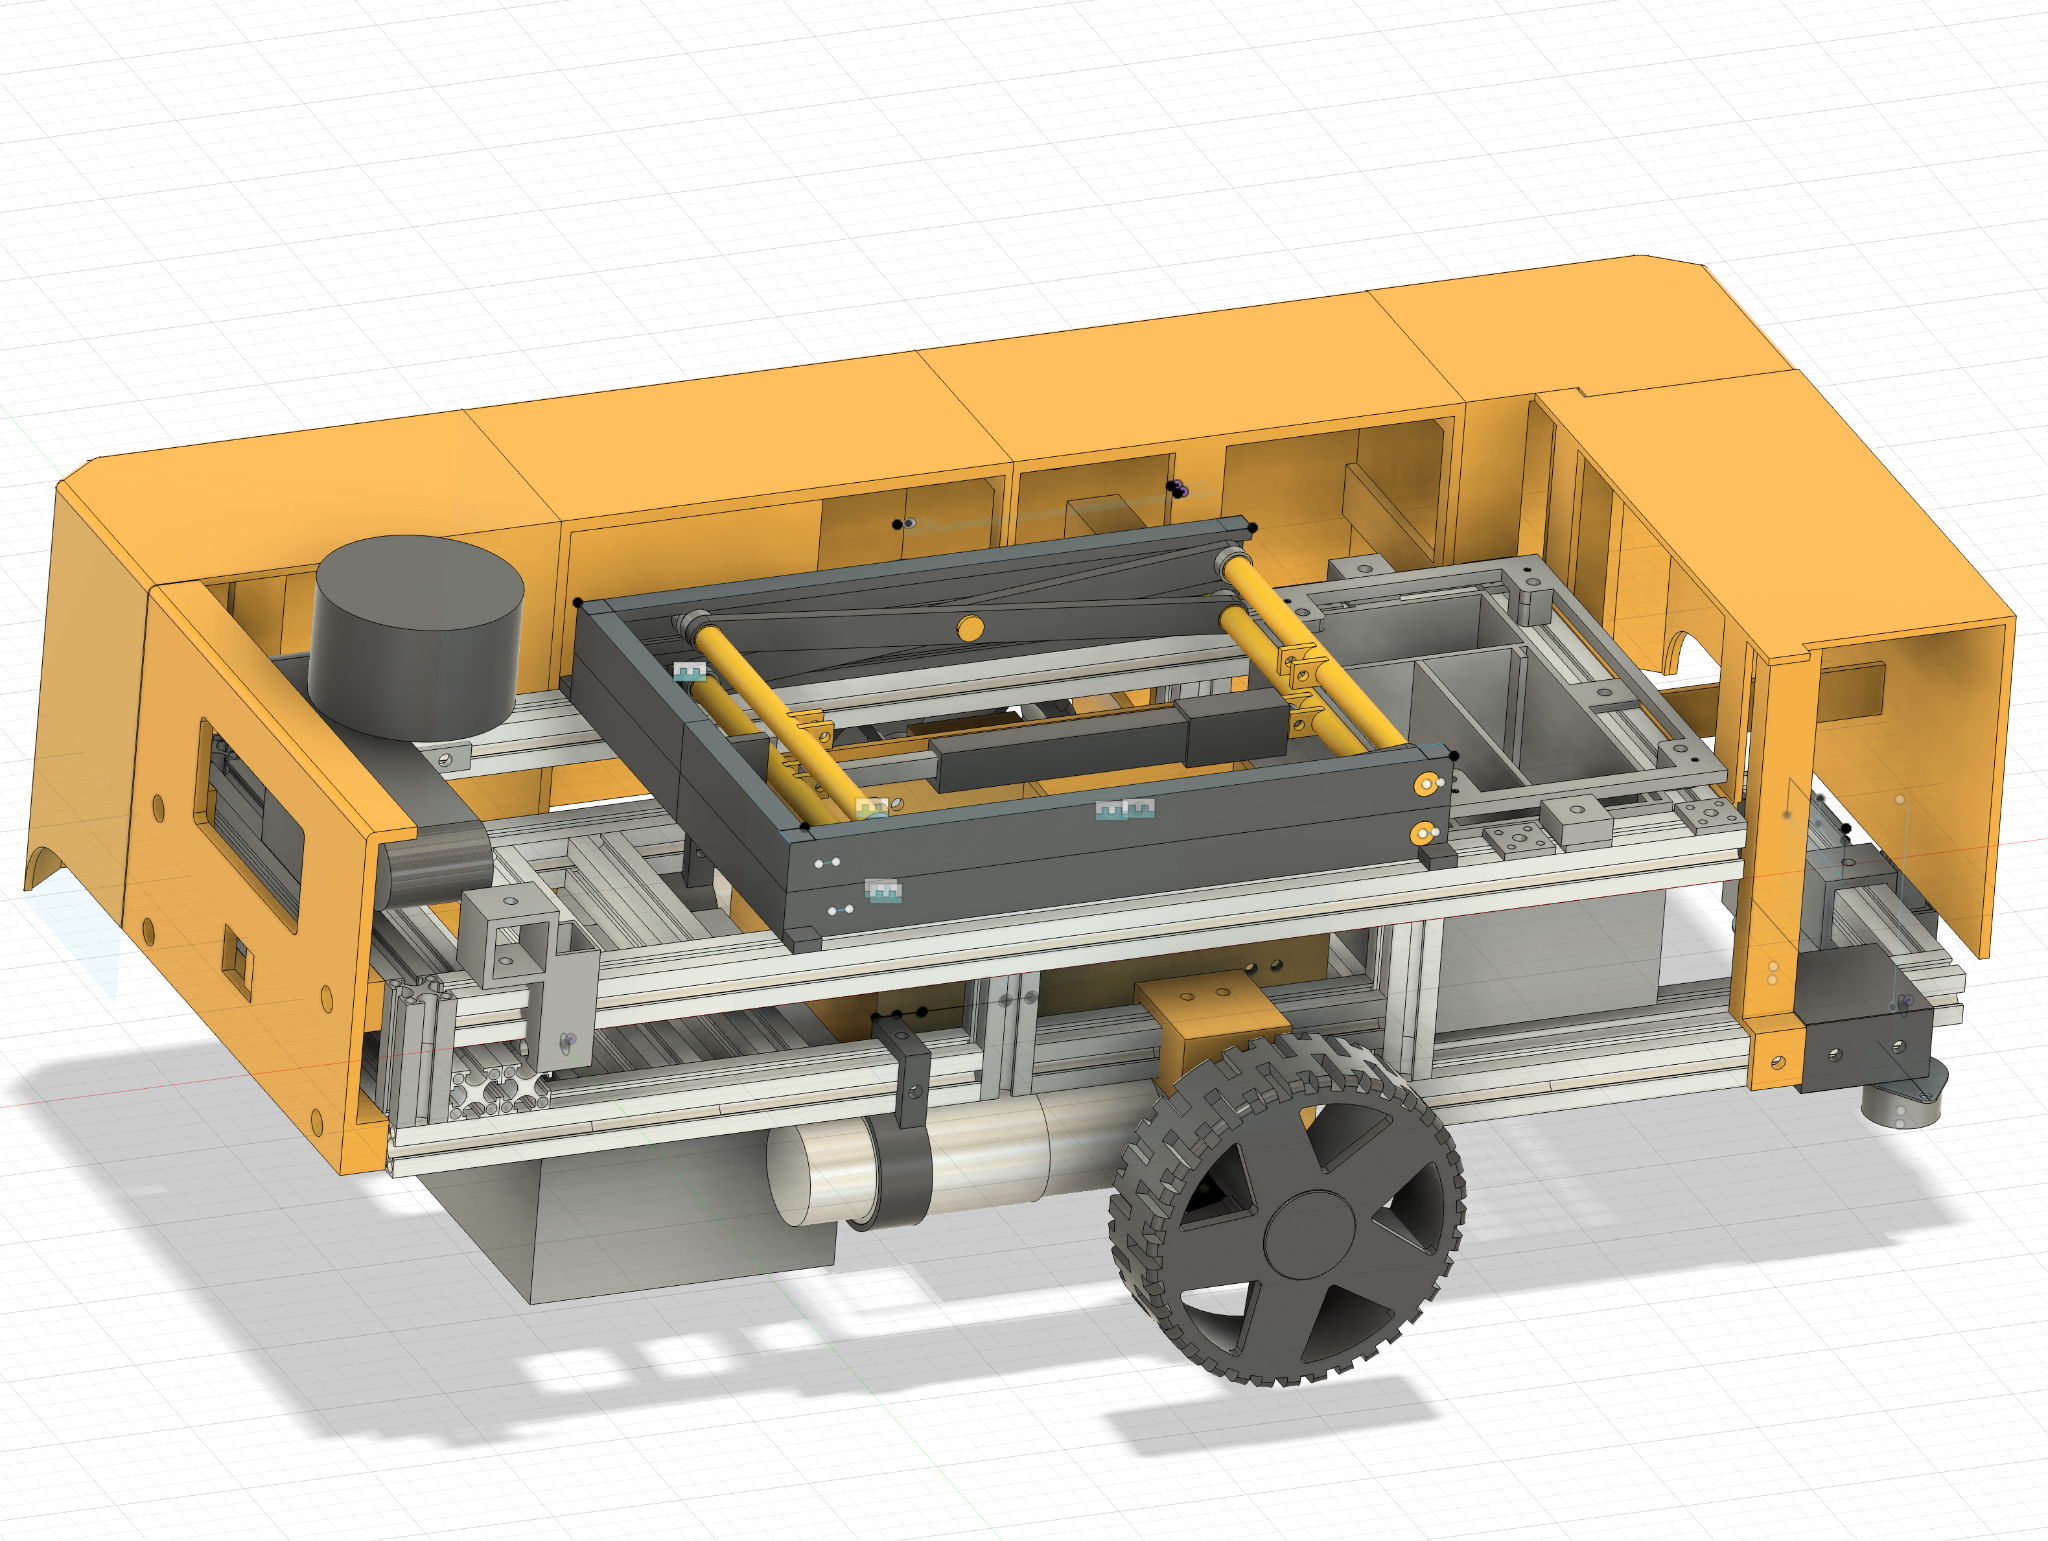
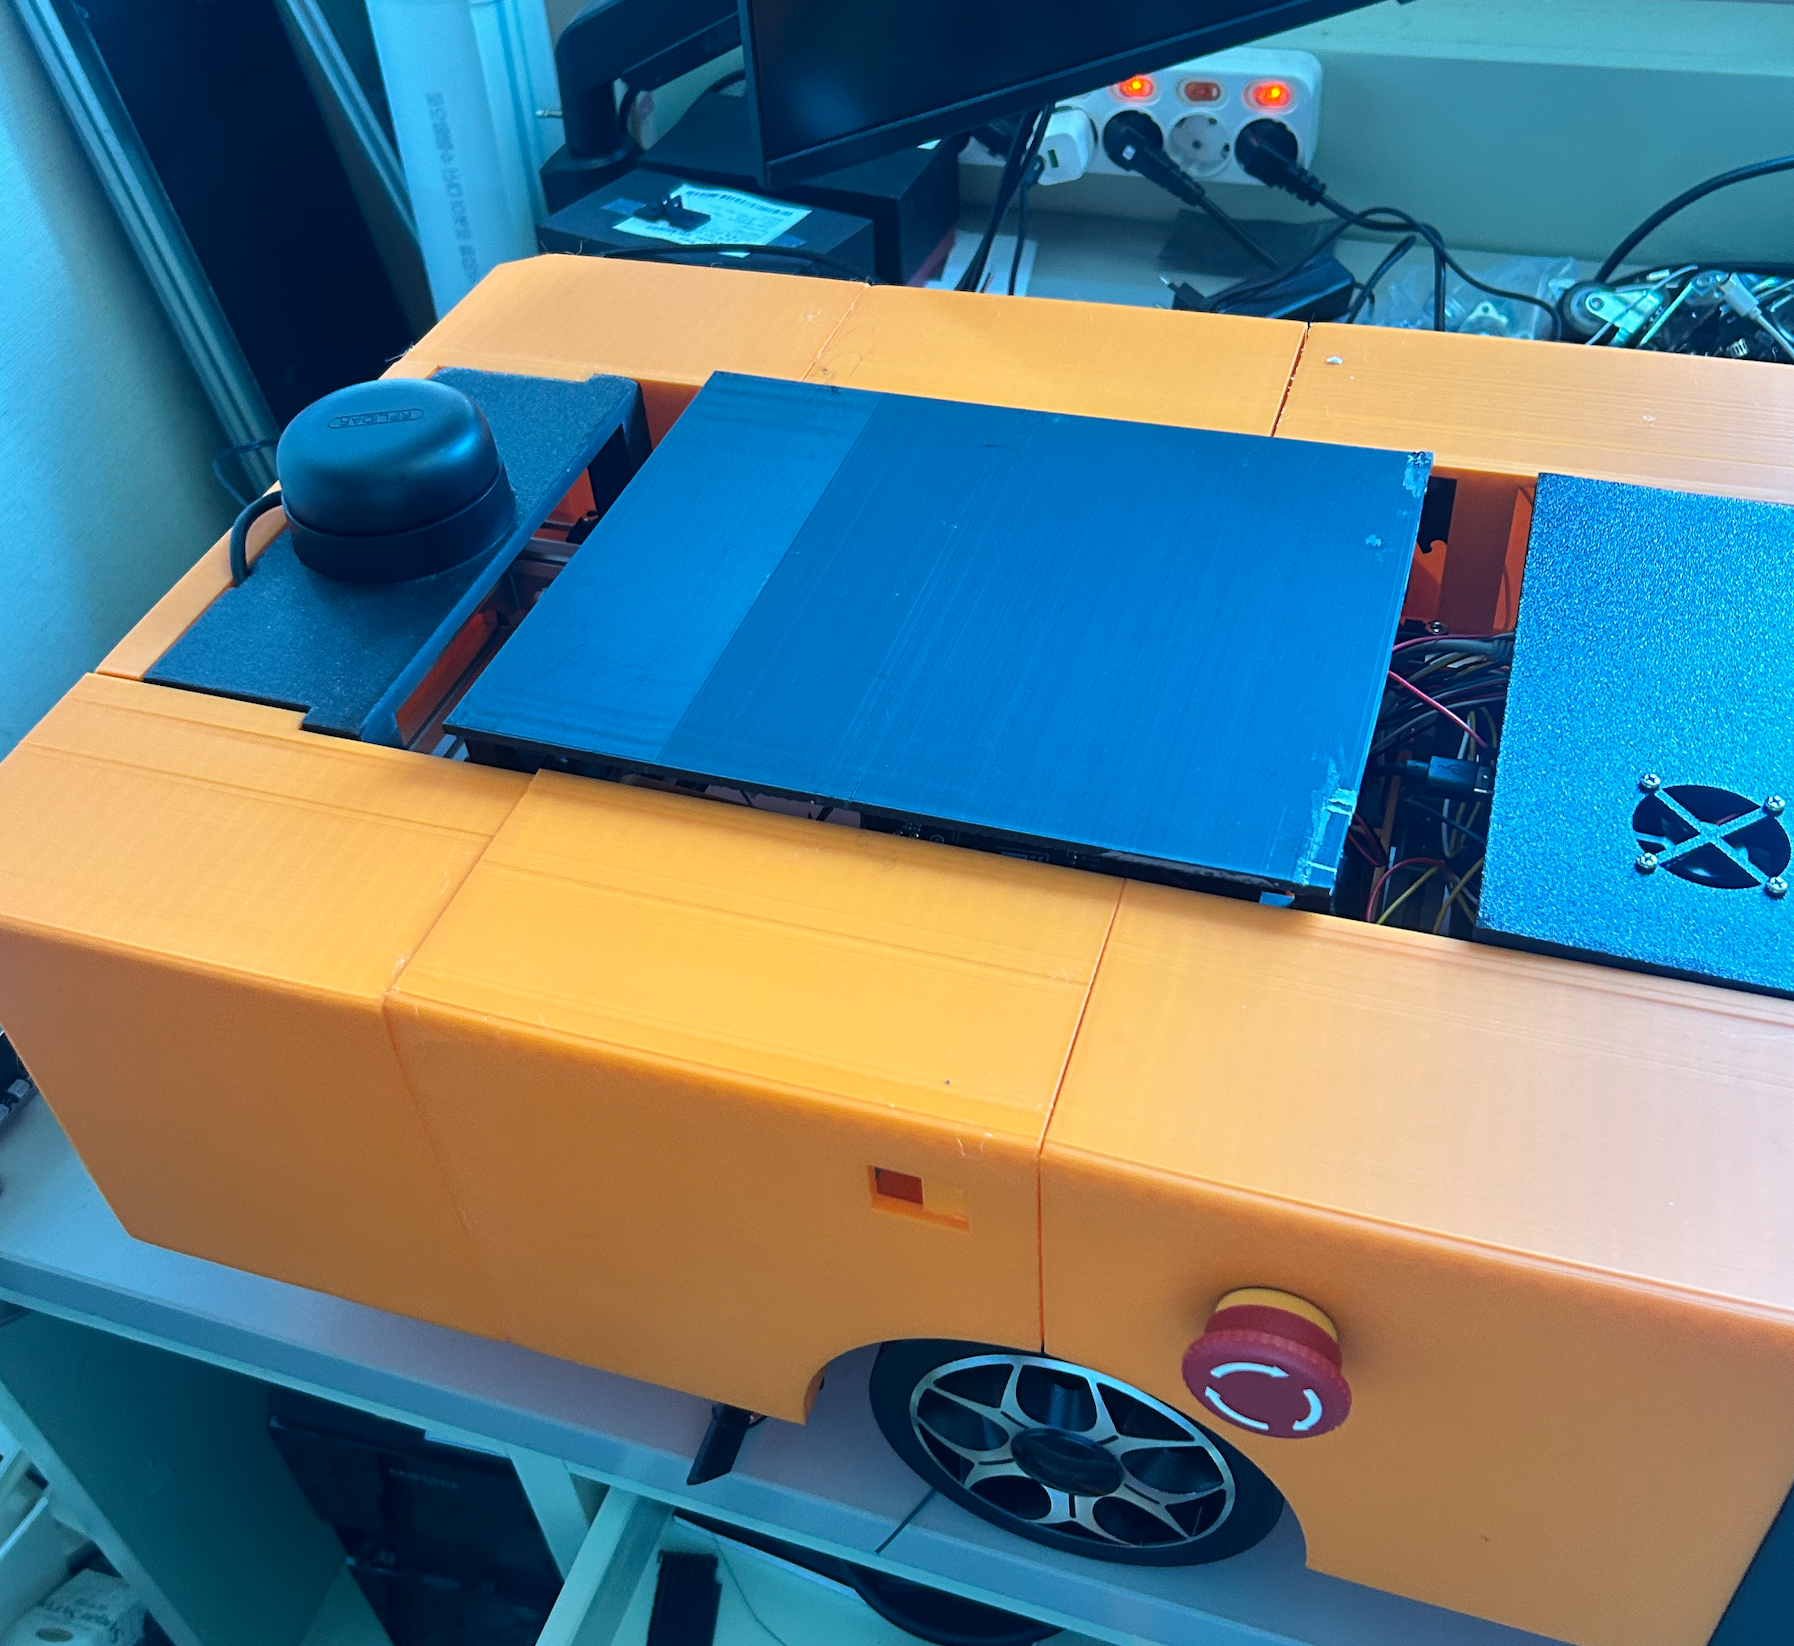
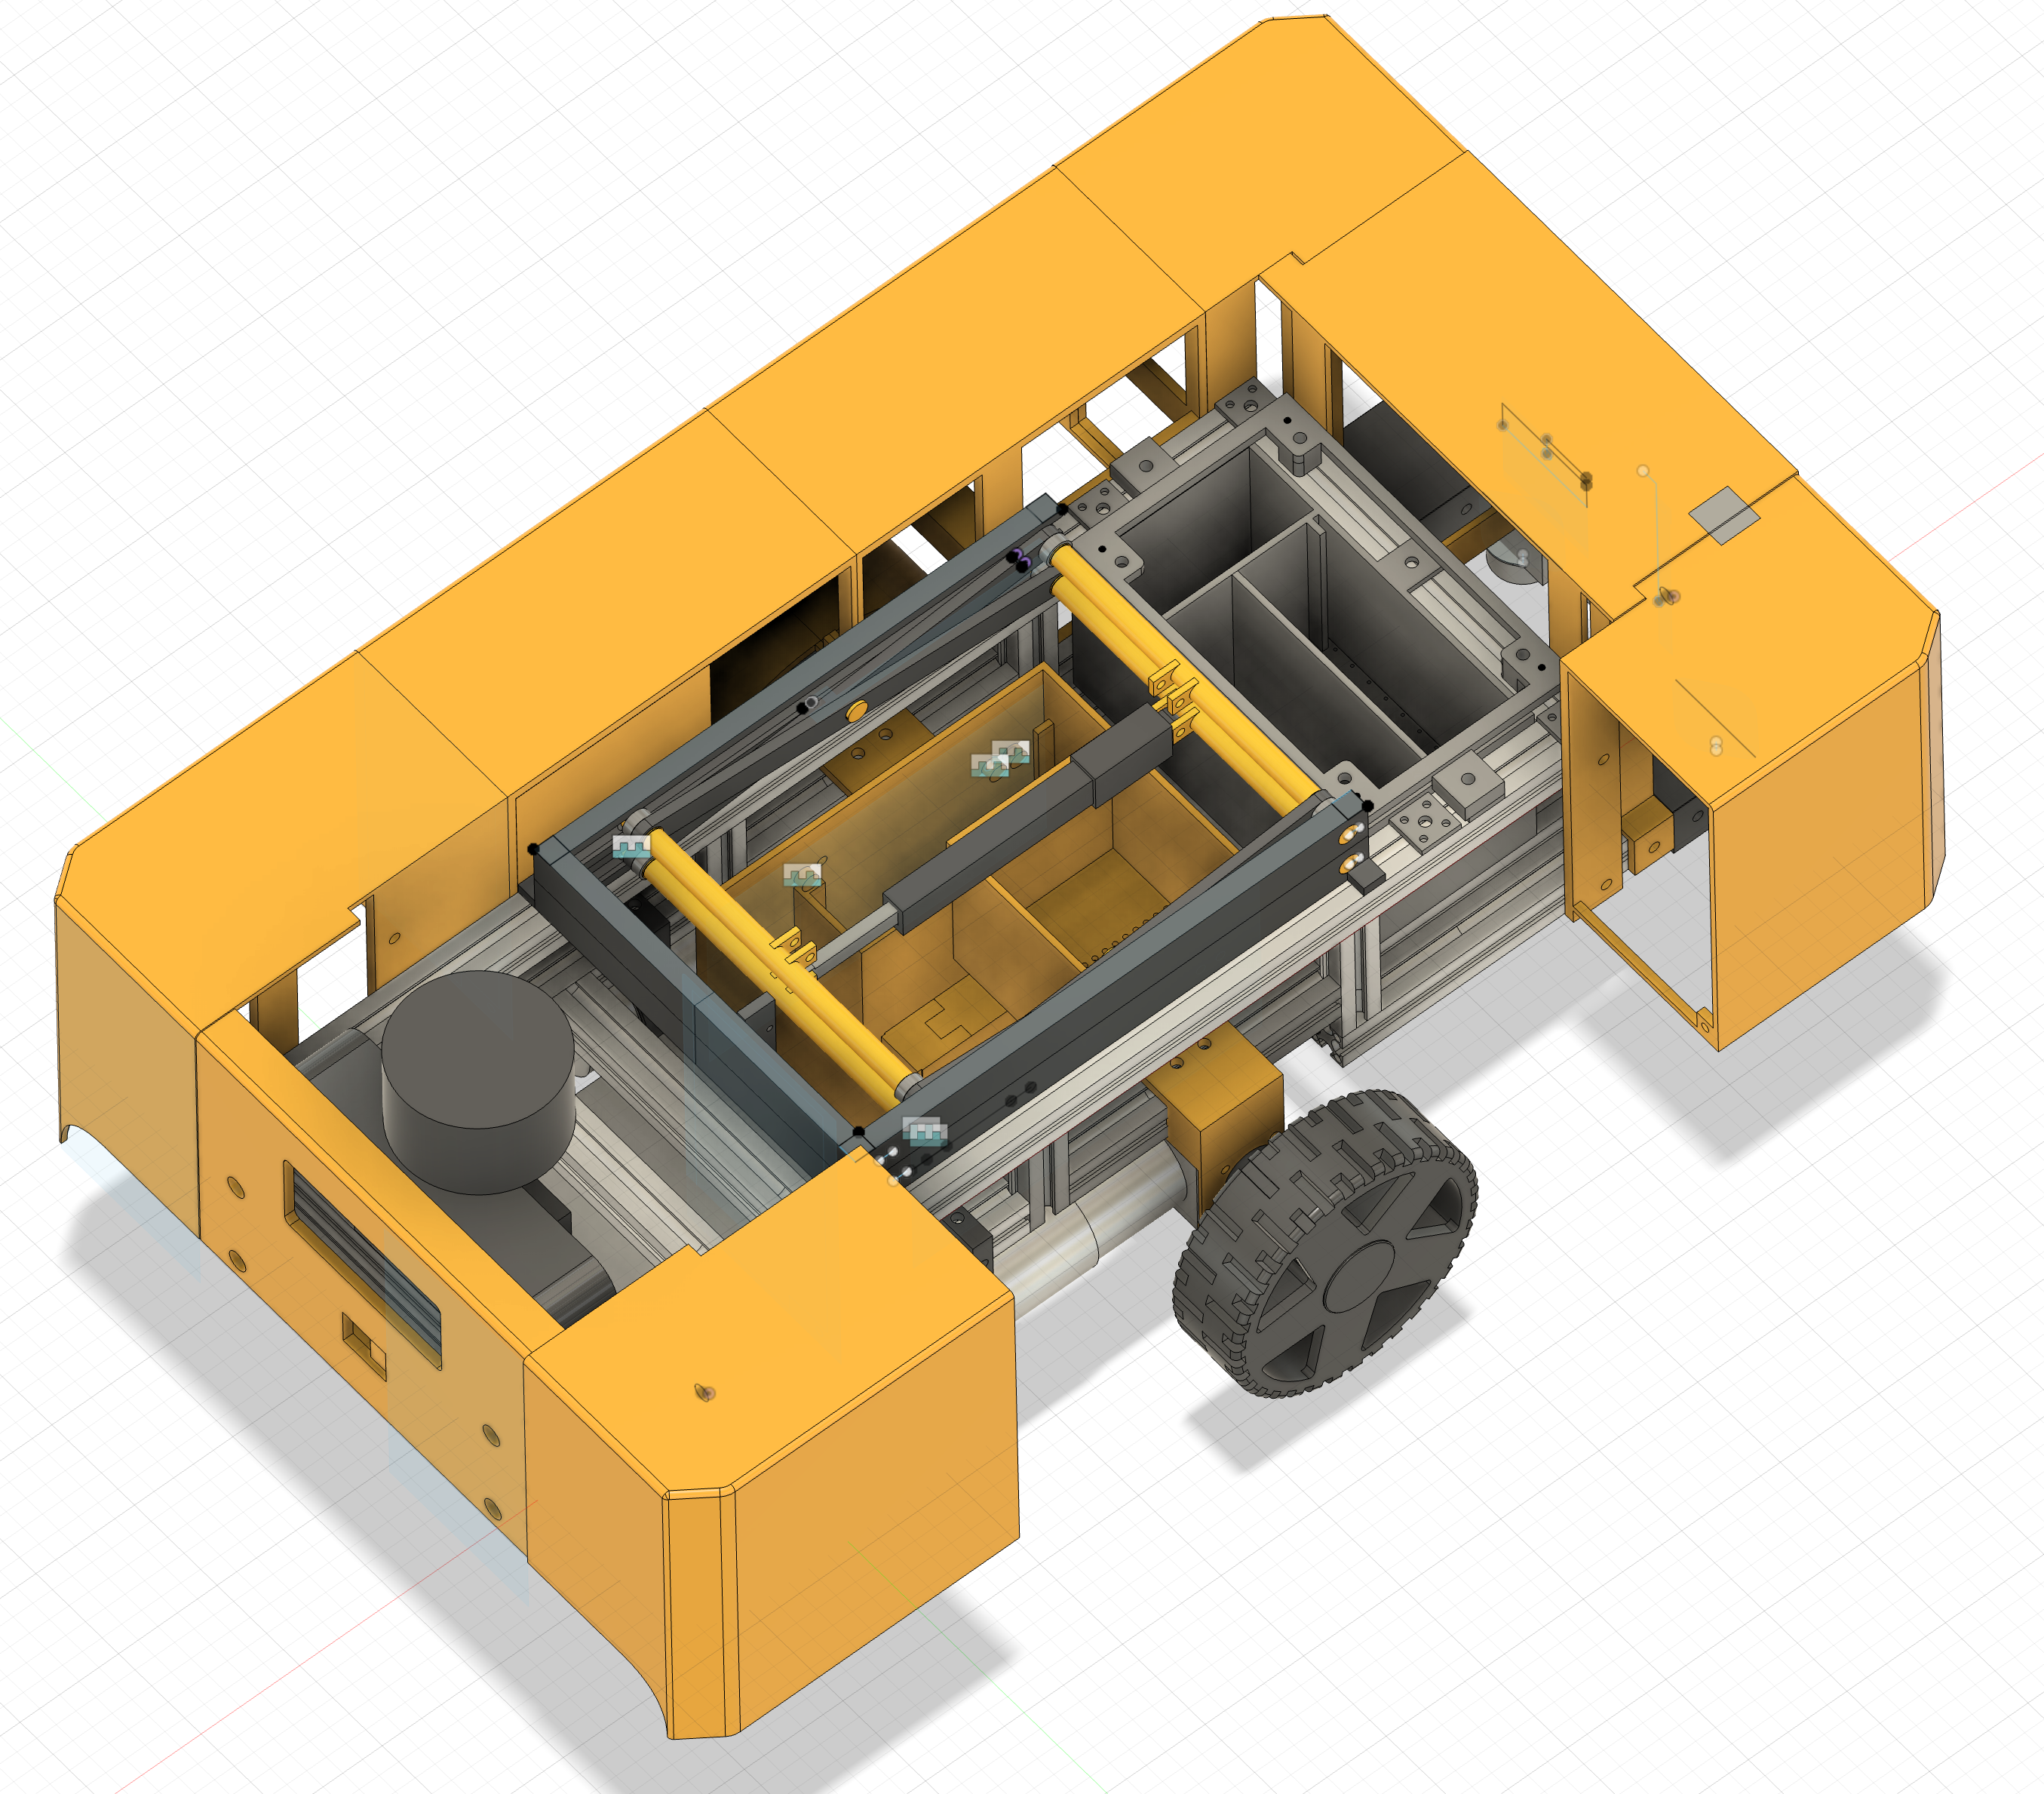
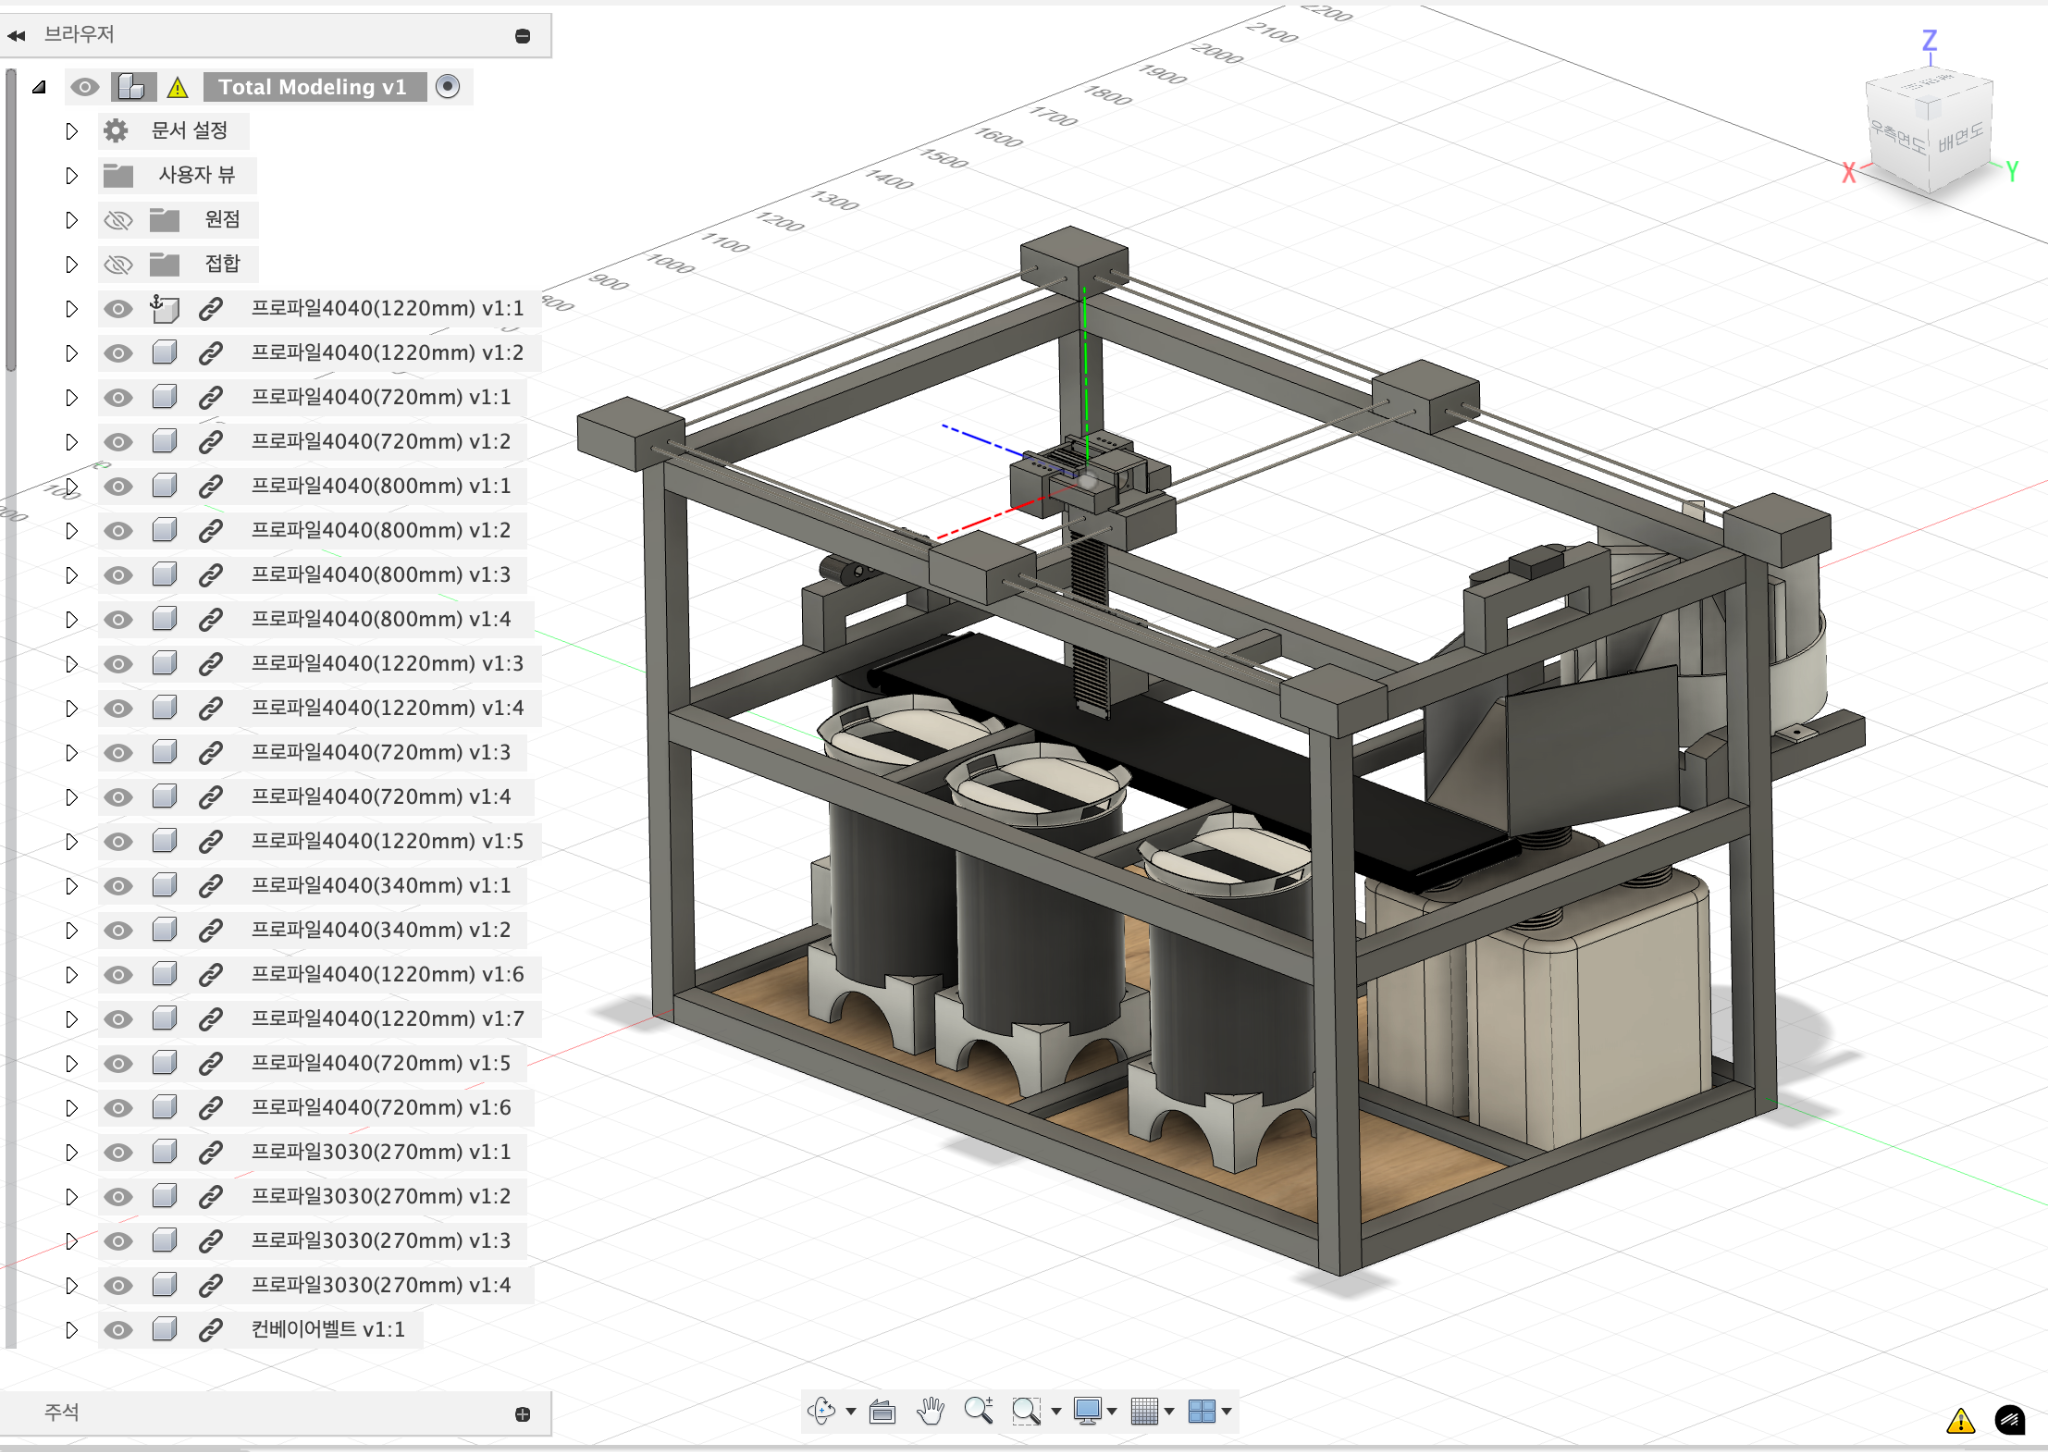
4인 팀의 자동 분리수거 시제품. 컨베이어 이송, 영상 인식·로봇 분류, 초음파 세척으로 구성. 담당: 전원·배선, 컨베이어 PWM 제어, 세척 장치, 장비 제작·시험, 터치 UI.
A four-person prototype combining conveyor transport, object sorting, robotic motion, and cleaning. Team members divided responsibilities across vision, motion, power, and fabrication.
전원 구성과 장비 제작·시험
Power integration, fabrication and testing
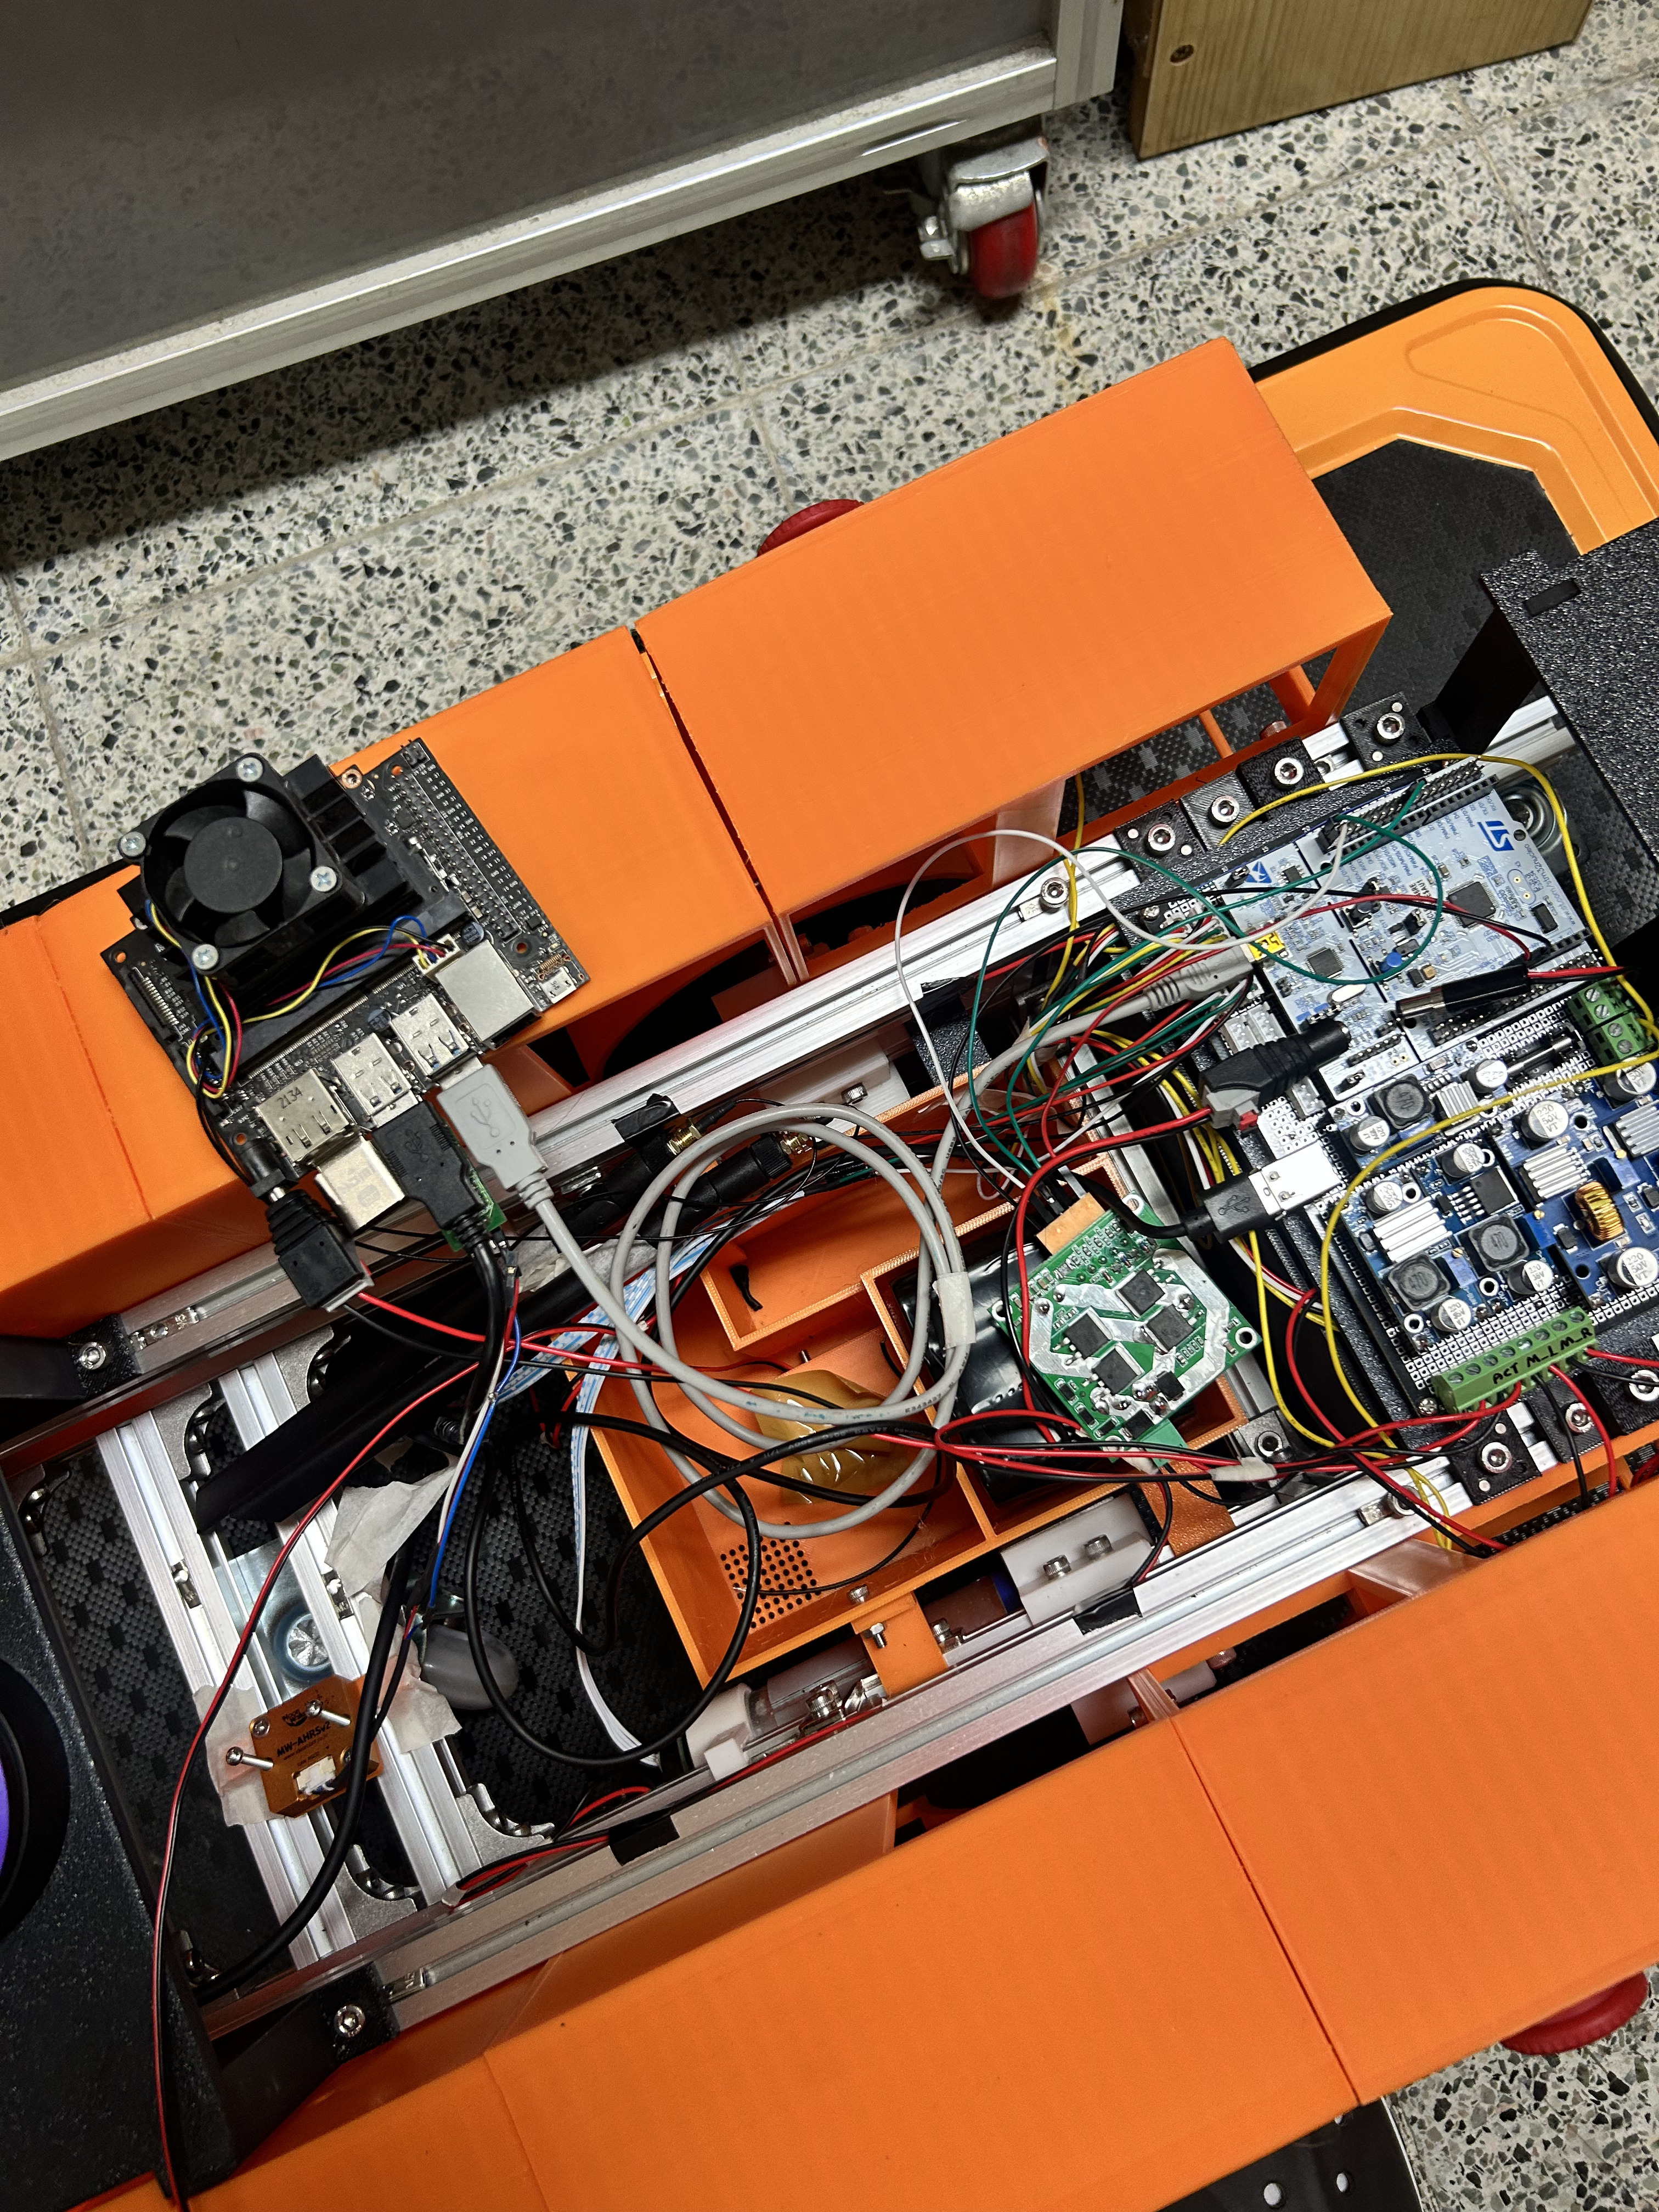
- 24V 주전원을 장치별 12V·5V 전원으로 나누어 공급
- DC 모터와 펌프 등 구동부의 전원 연결·배선 구성
- 컨베이어 PWM·시간 제어 구현, 별도 엔코더 모터 PID 튜닝
- 구동 중 발생한 문제 점검 및 재시험
- Raspberry Pi·Python 터치 UI 및 관리자 제어 기능 구성
- Distributed a 24V supply into 12V and 5V paths
- Integrated power and wiring for DC motors and other loads
- Implemented conveyor PWM/time control; tuned PID on a separate encoder motor
- Checked faults and retested equipment
- Built a Raspberry Pi/Python touch interface and administrator controls
전원을 연결하고, 함께 구동하며 확인
Integrated and tested the system
- 각 장치에 필요한 전압을 확인하고 전원 경로 구성
- DC 모터·제어부·기타 장치를 연결해 조립
- 개별 구동과 전체 장비 구동을 반복 확인
- DC-DC 컨버터 파손 발생 → 전원 분배 방식 수정
- Checked voltage requirements and planned power paths
- Connected motors, controller and other loads
- Tested individual loads and the assembled system
- Responded to a failed DC-DC converter by reallocating supply paths
DC 모터 전원 경로 분리와 장비 재검증
Dedicated motor power paths and system retesting
변경 전 · 전원 경로 공유Before · Shared supply path
변경 후 · 모터별 전원 경로 분리After · Separate motor supply paths
↓
각 DC 모터Dedicated DC-DC paths
↓
Individual DC motors
↓
기타 12V 부하Separate 12V paths
↓
Other 12V loads
변경한 12V 전원 경로를 요약한 개념도. 전체 배선·연결 구성은 아래 KiCad 도면 참고.
Conceptual summary of the revised 12V paths. See the KiCad drawings below for the documented wiring configuration.
검증 범위와 다음 설계에서 확인할 항목
Validation scope and next design checks
검증 범위 · 당시 시험의 세부 계측값과 기동 전류·출력 전압 파형은 남아 있지 않아 파손 원인을 단일 요인으로 확정하지 않음. 아래 KiCad 도면은 제작 후 실제 전원·배선 구성을 정리한 자료로, PCB 설계나 도면상 피크 전류의 실측 증빙이 아님.
Validation scope · Detailed readings and startup-current/output-voltage waveforms were not retained; the failure is not attributed to a proven single cause. The KiCad drawings document the final wiring retrospectively, rather than PCB design or measured peak-current results.
추가 검증 계획 · 기동·정상 구동 전류와 12V 출력 전압 변화를 기록하고, 동시 부하에서 컨버터 용량·발열 여유 및 보호 동작 확인. 당시 수행 결과와 구분한 향후 검증 항목.
Proposed next checks · Record startup/steady-state current and 12V output-voltage changes; verify converter capacity, thermal margin and protection under simultaneous loads. These checks are proposed work, not historical results.
문제 해결 02 · 엔코더 신호 이상과 PID 적용 제한
Issue 2 — Encoder Signal Fault and Control Approach
Evidence
Evidence
실제 제작·계측·세척 시험 자료
사진과 도면은 클릭하면 크게 볼 수 있음.
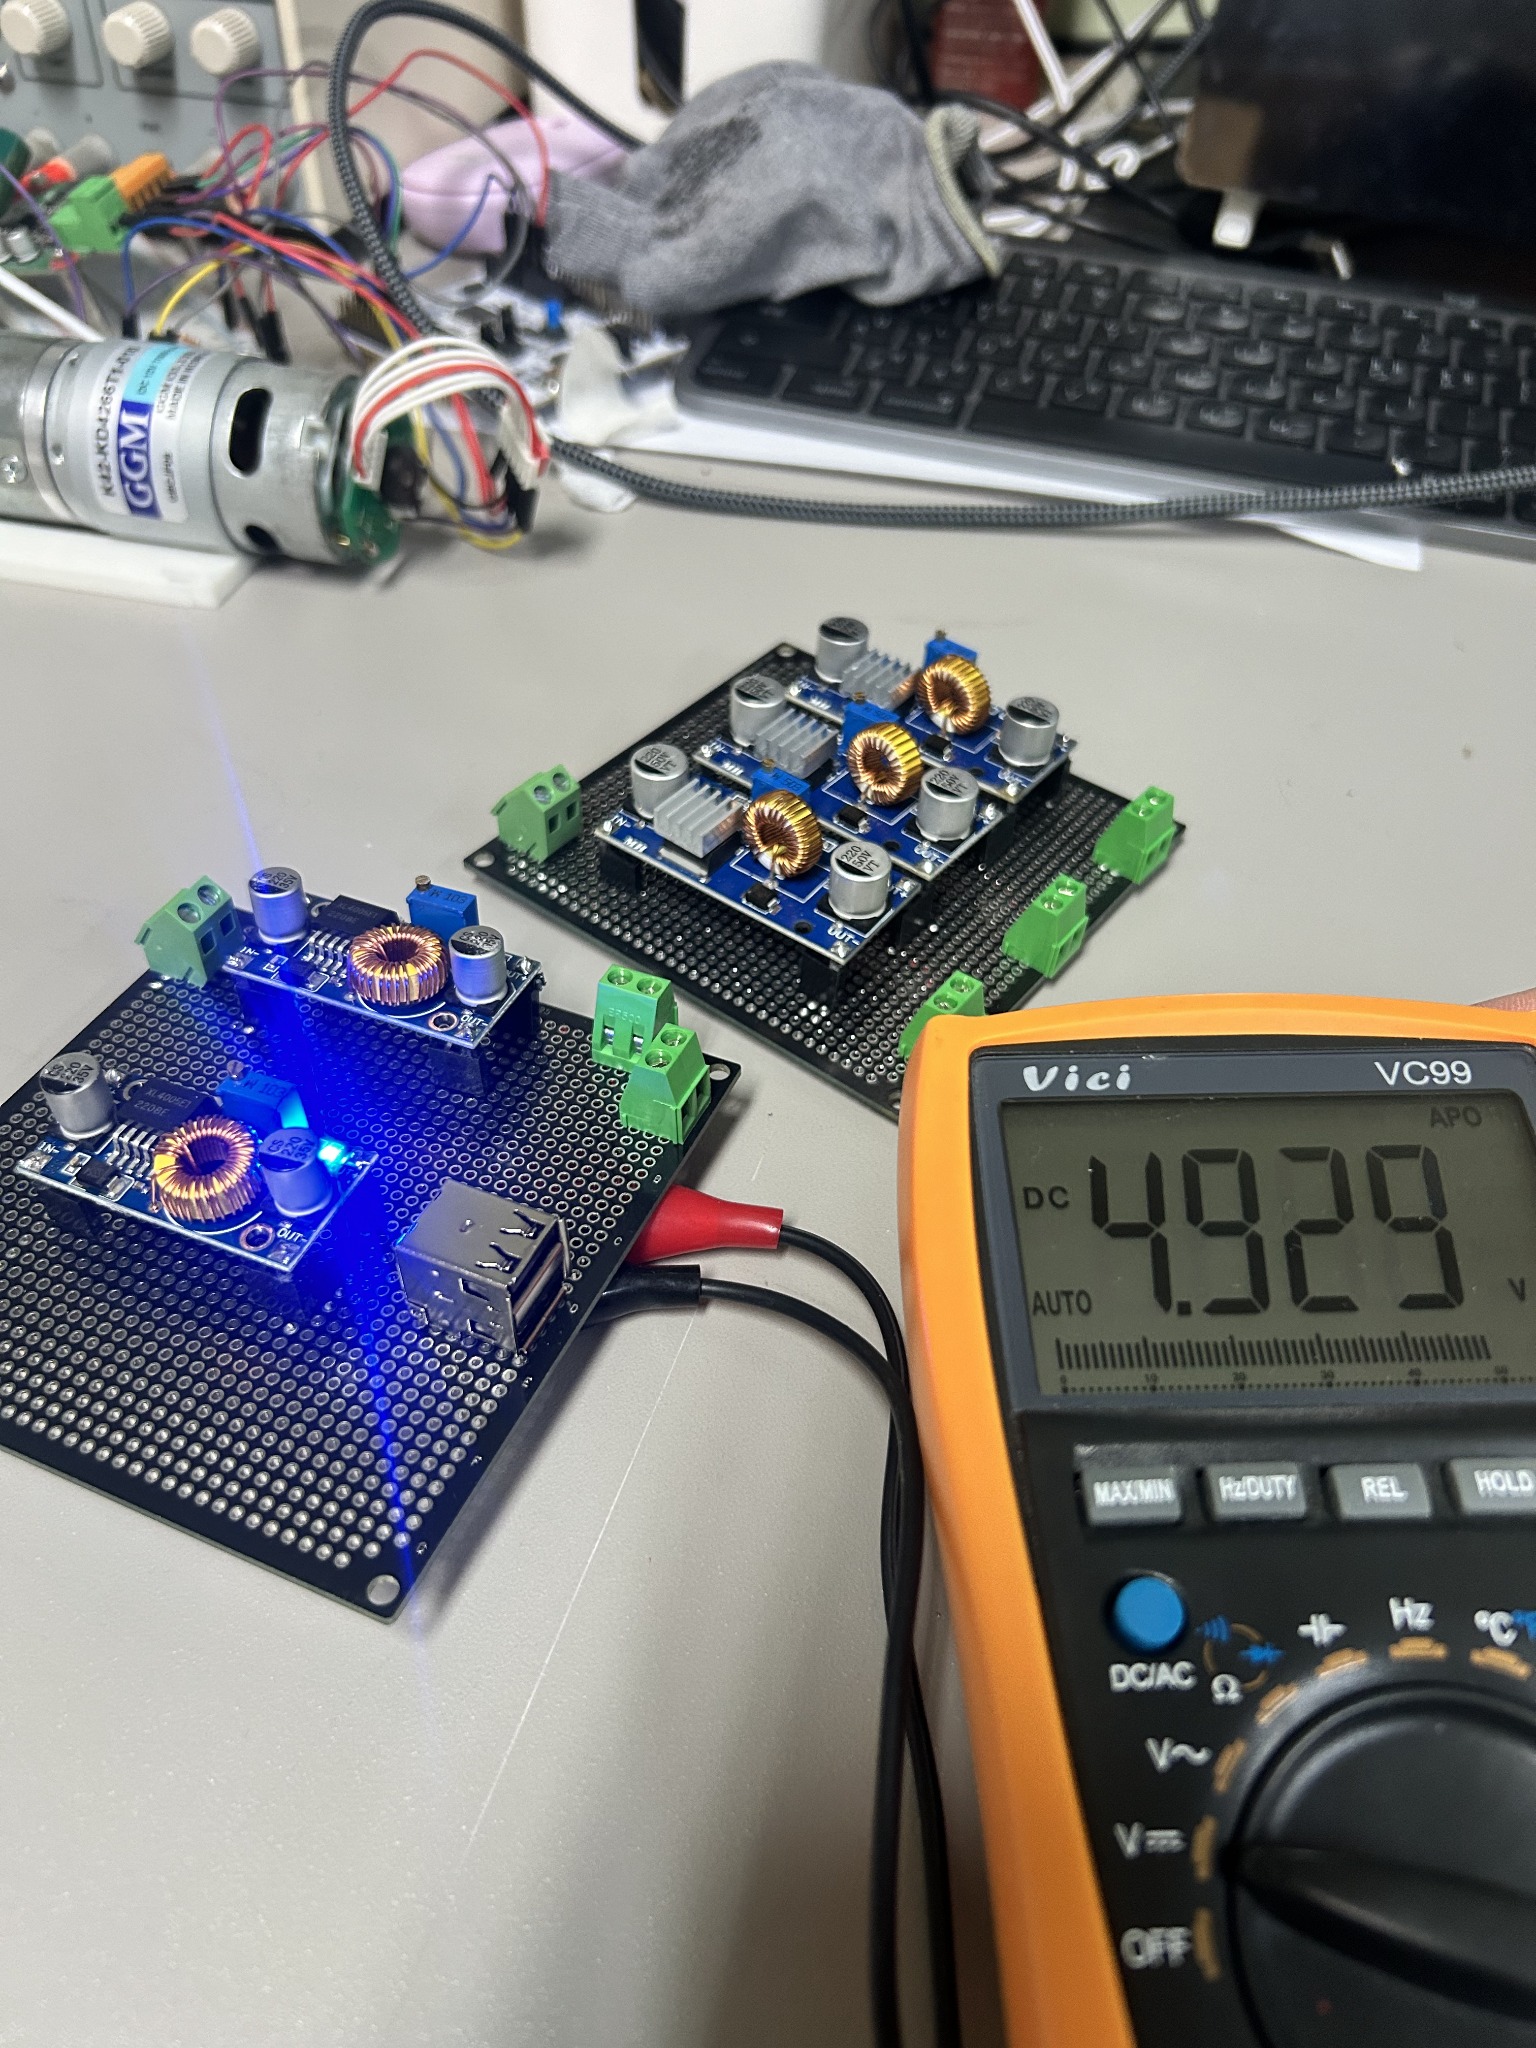
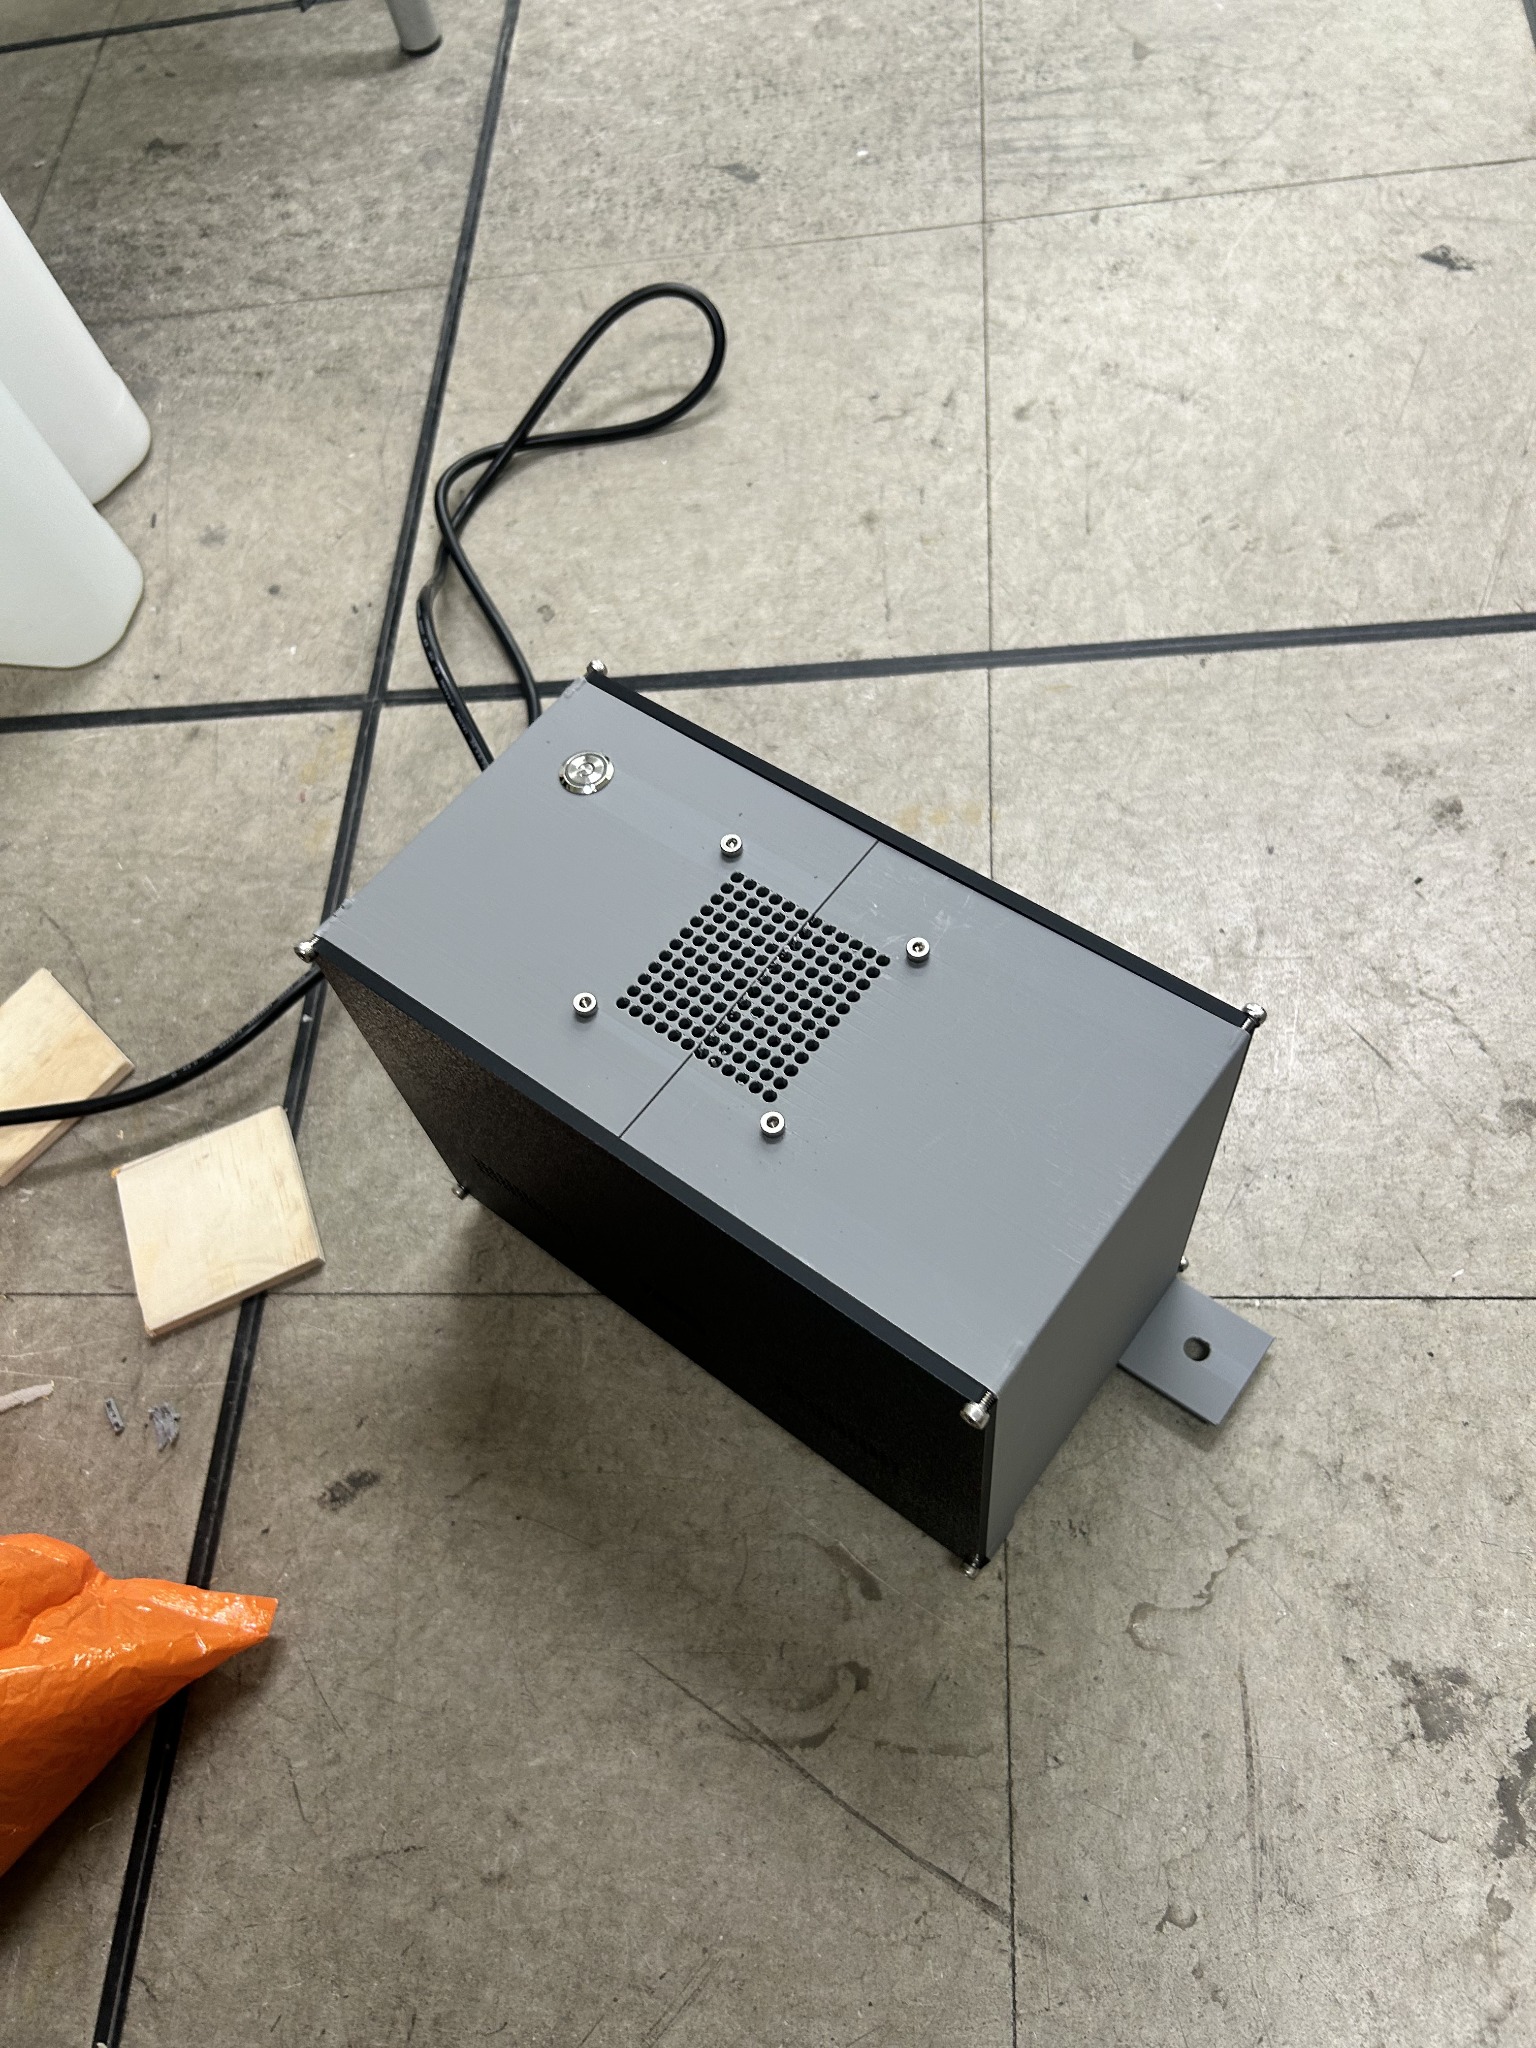
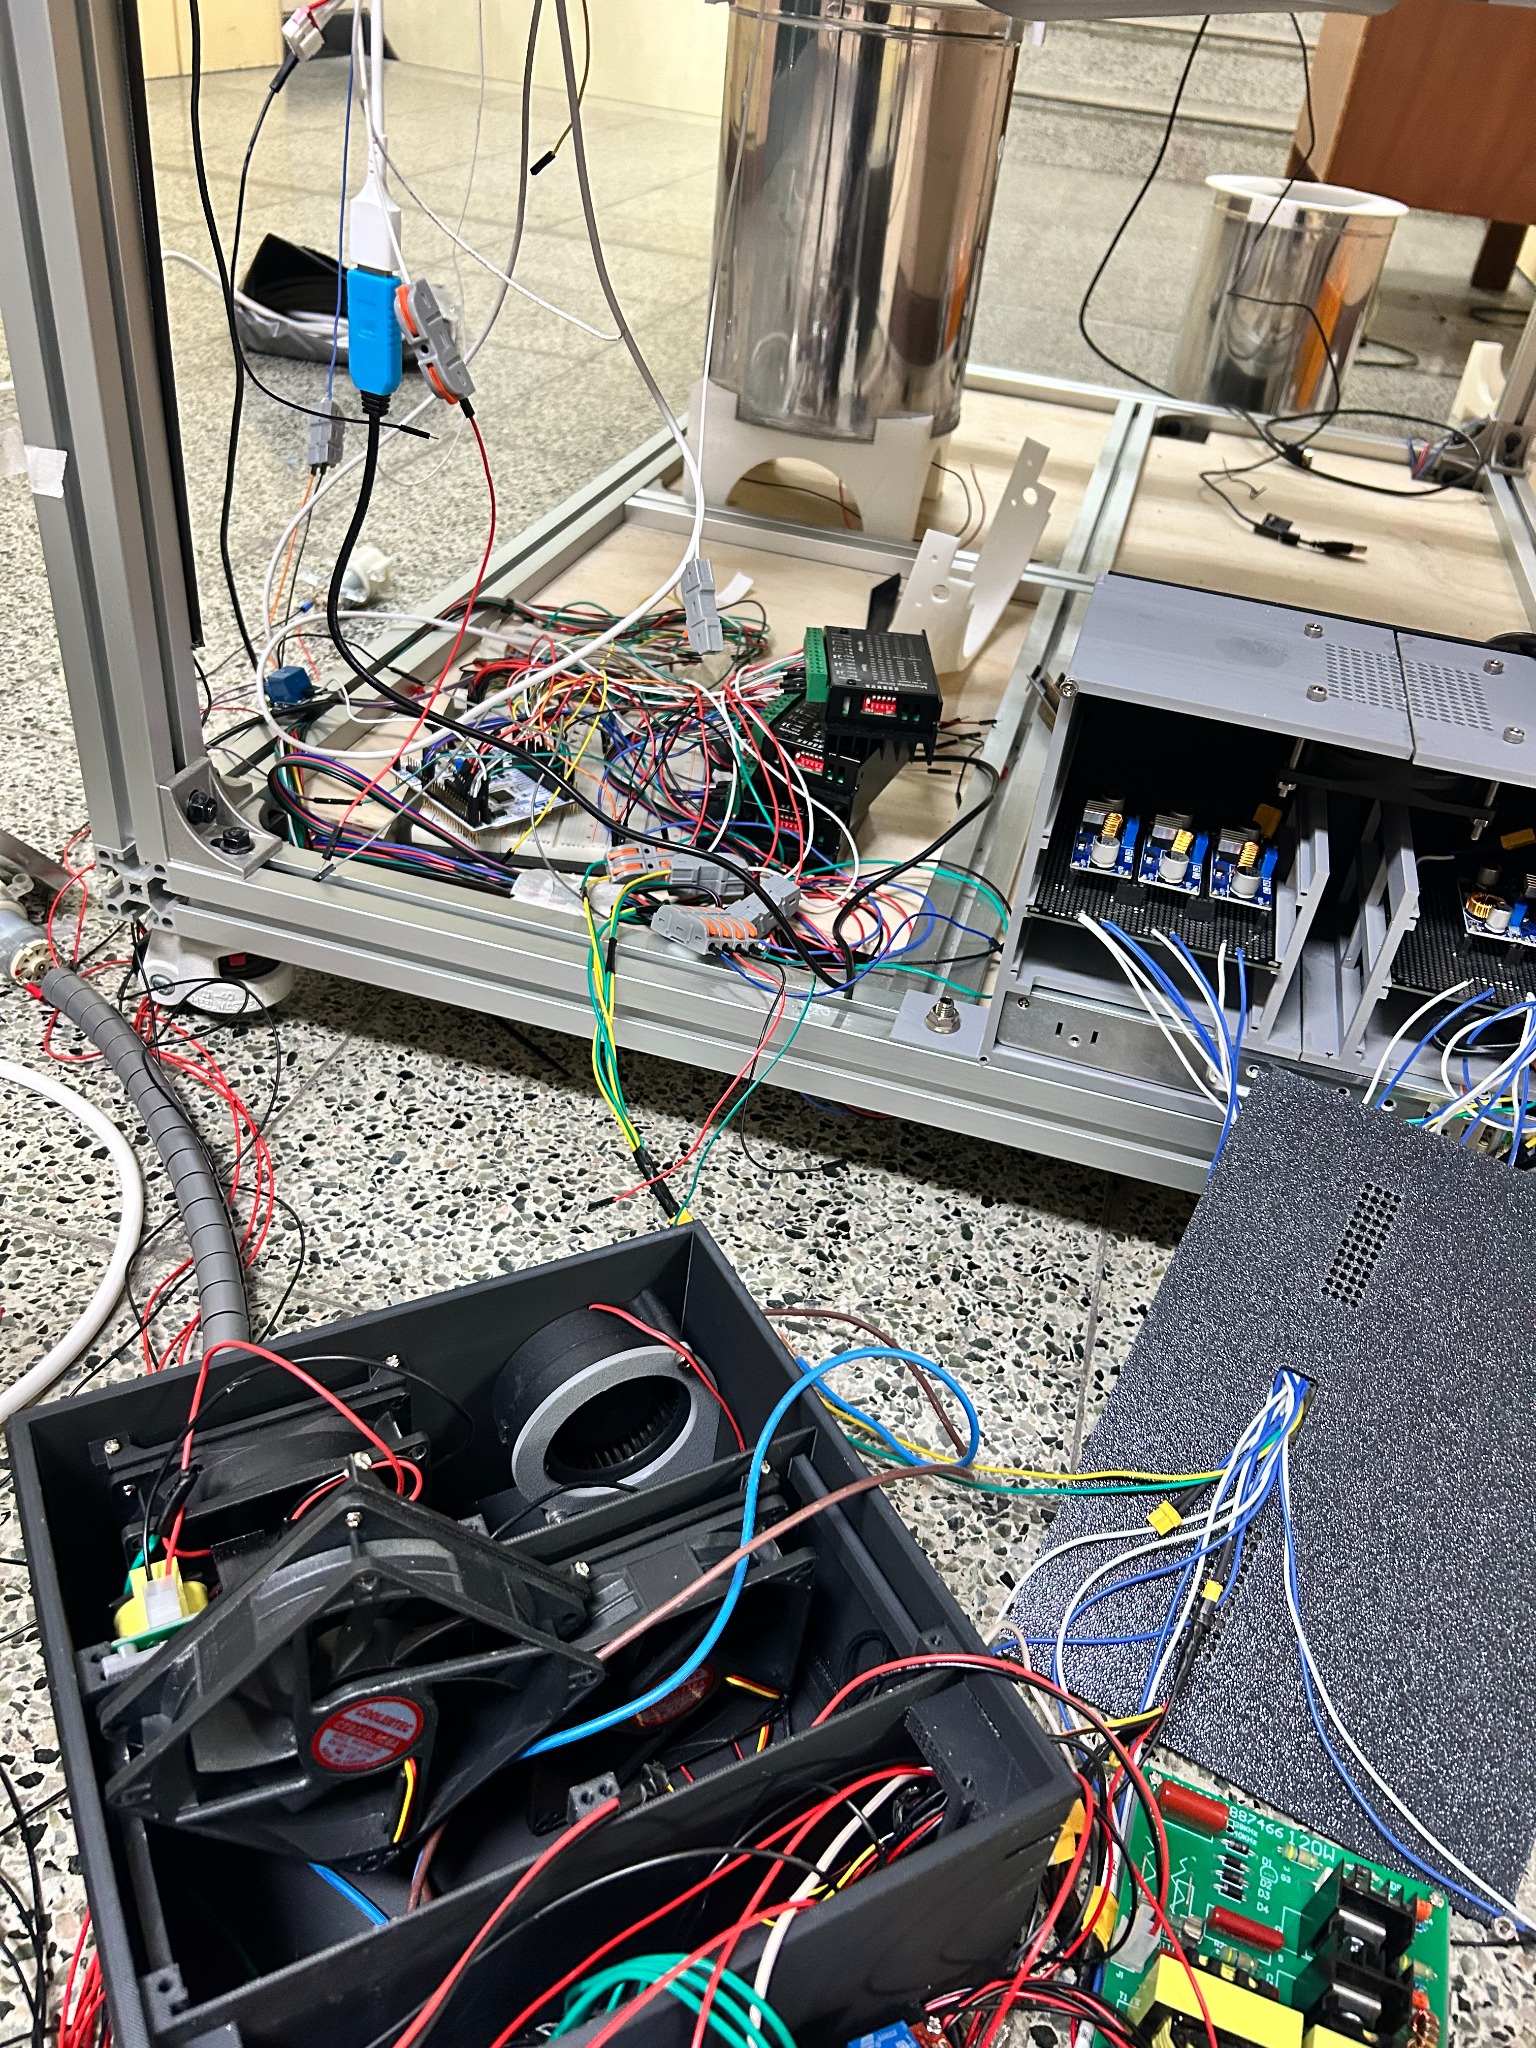
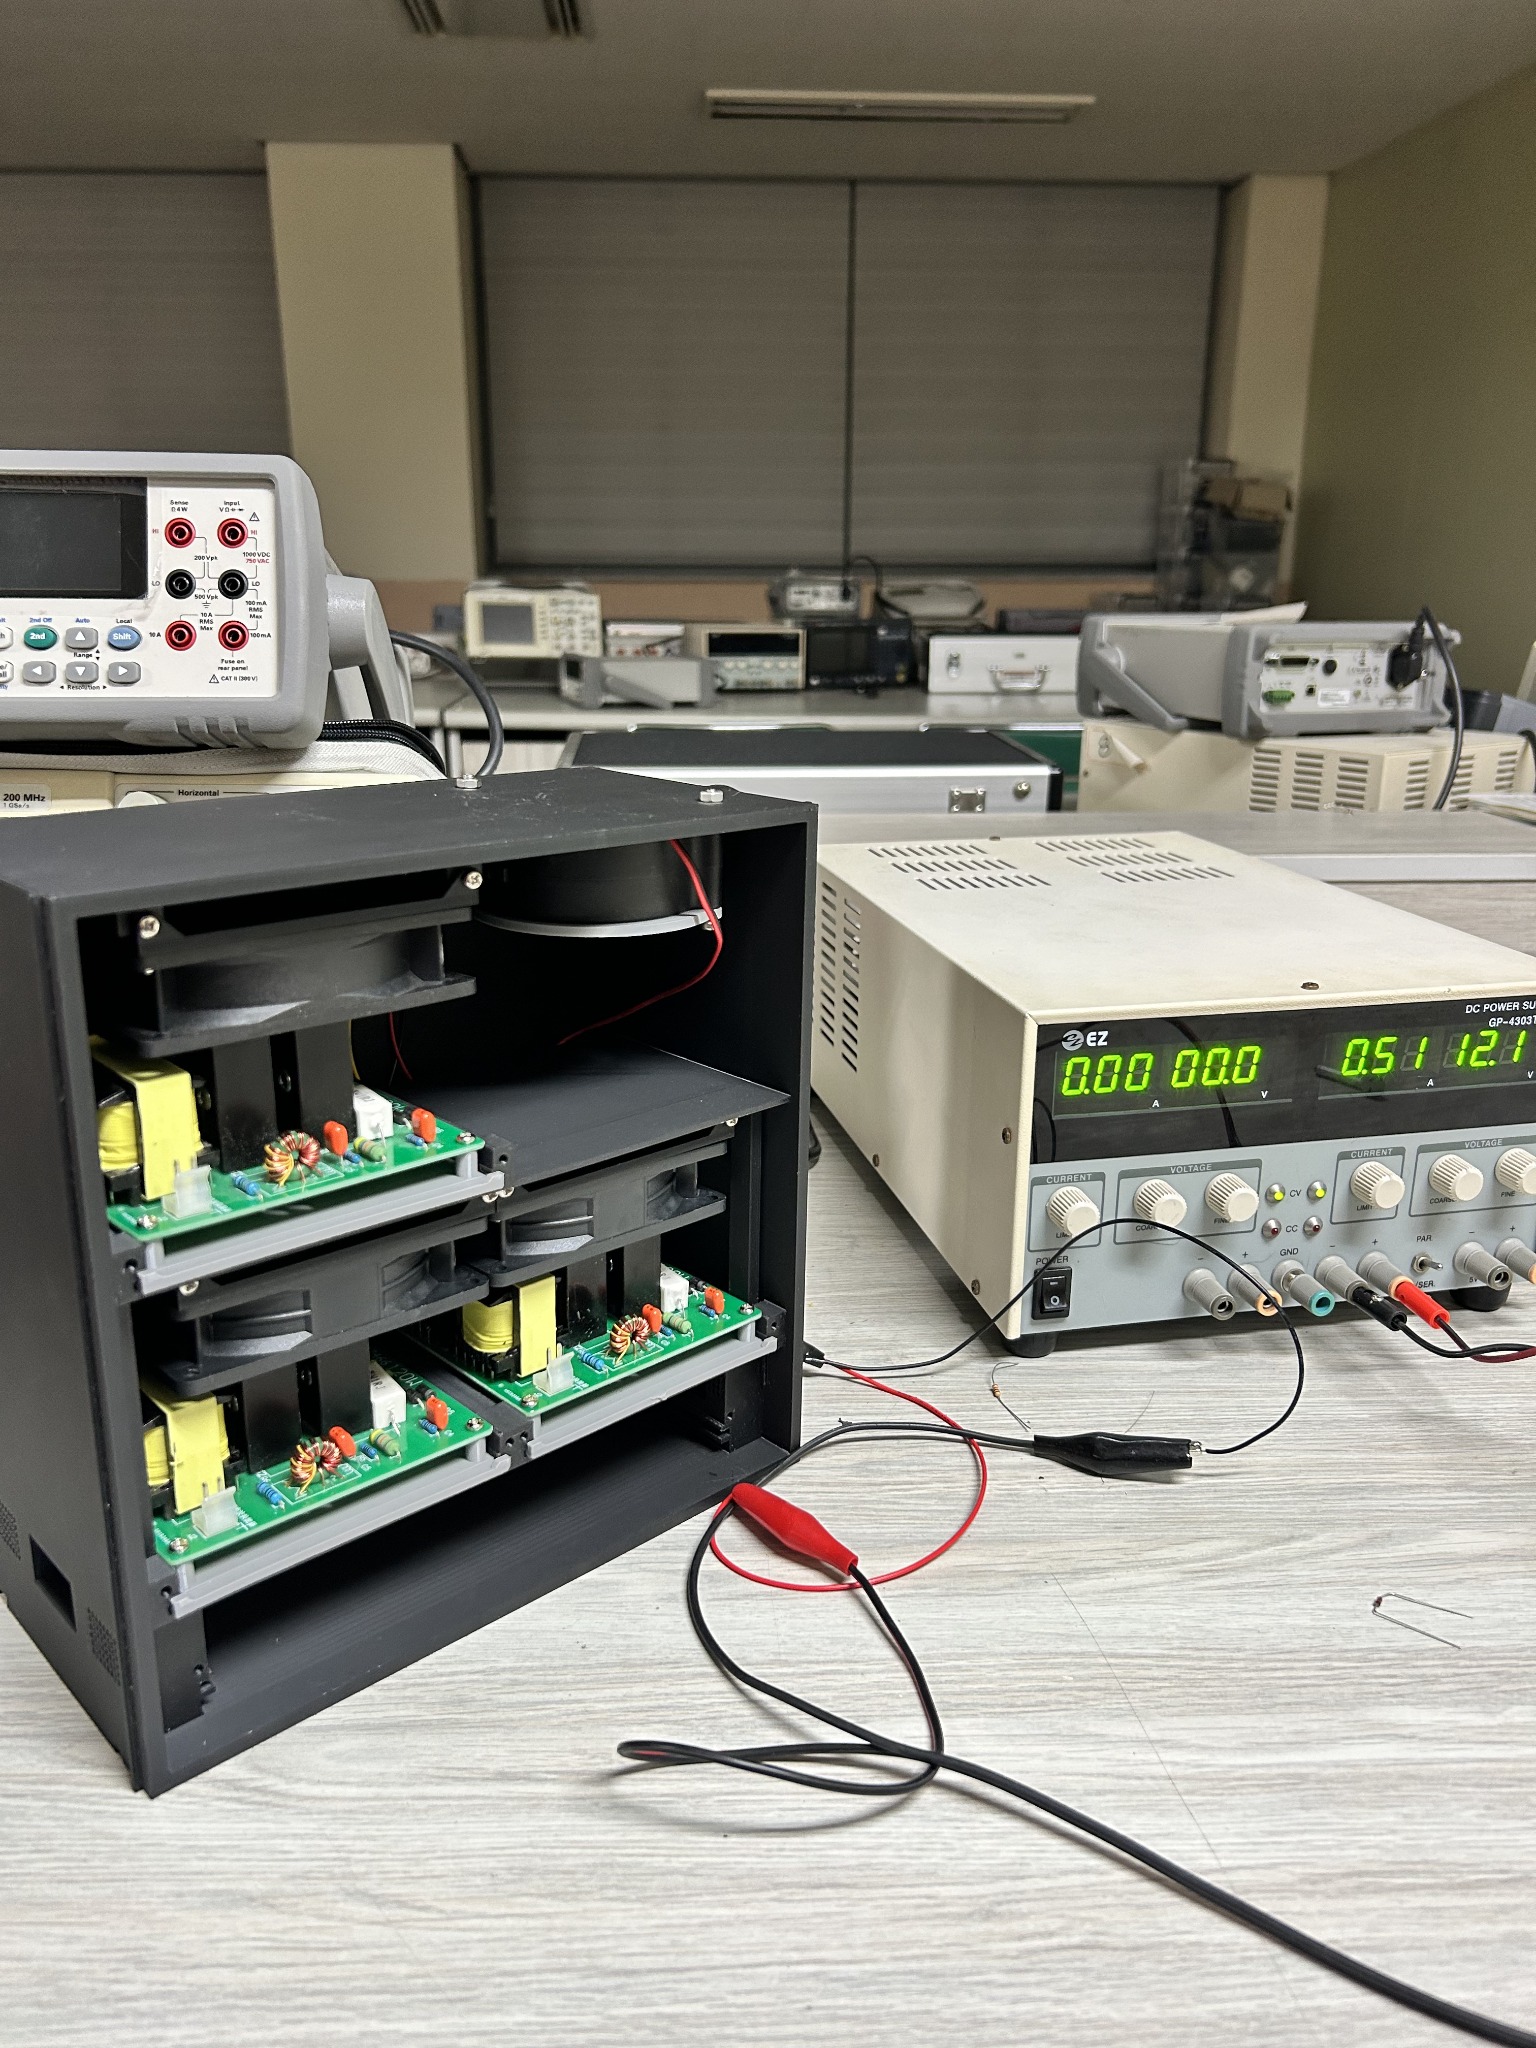
실제 컨베이어 모터의 전원·구동 시험 기록
초음파 세척 구동 및 세척 결과 (실제 가동 약 2분 · 영상 약 5배속)
실제 세척 약 2분, 영상 약 5배속 편집.
전원 분배·릴레이 구성도
시판 DC-DC 모듈·릴레이와 장치 간 실제 연결을 정리한 전원·배선 구성도.
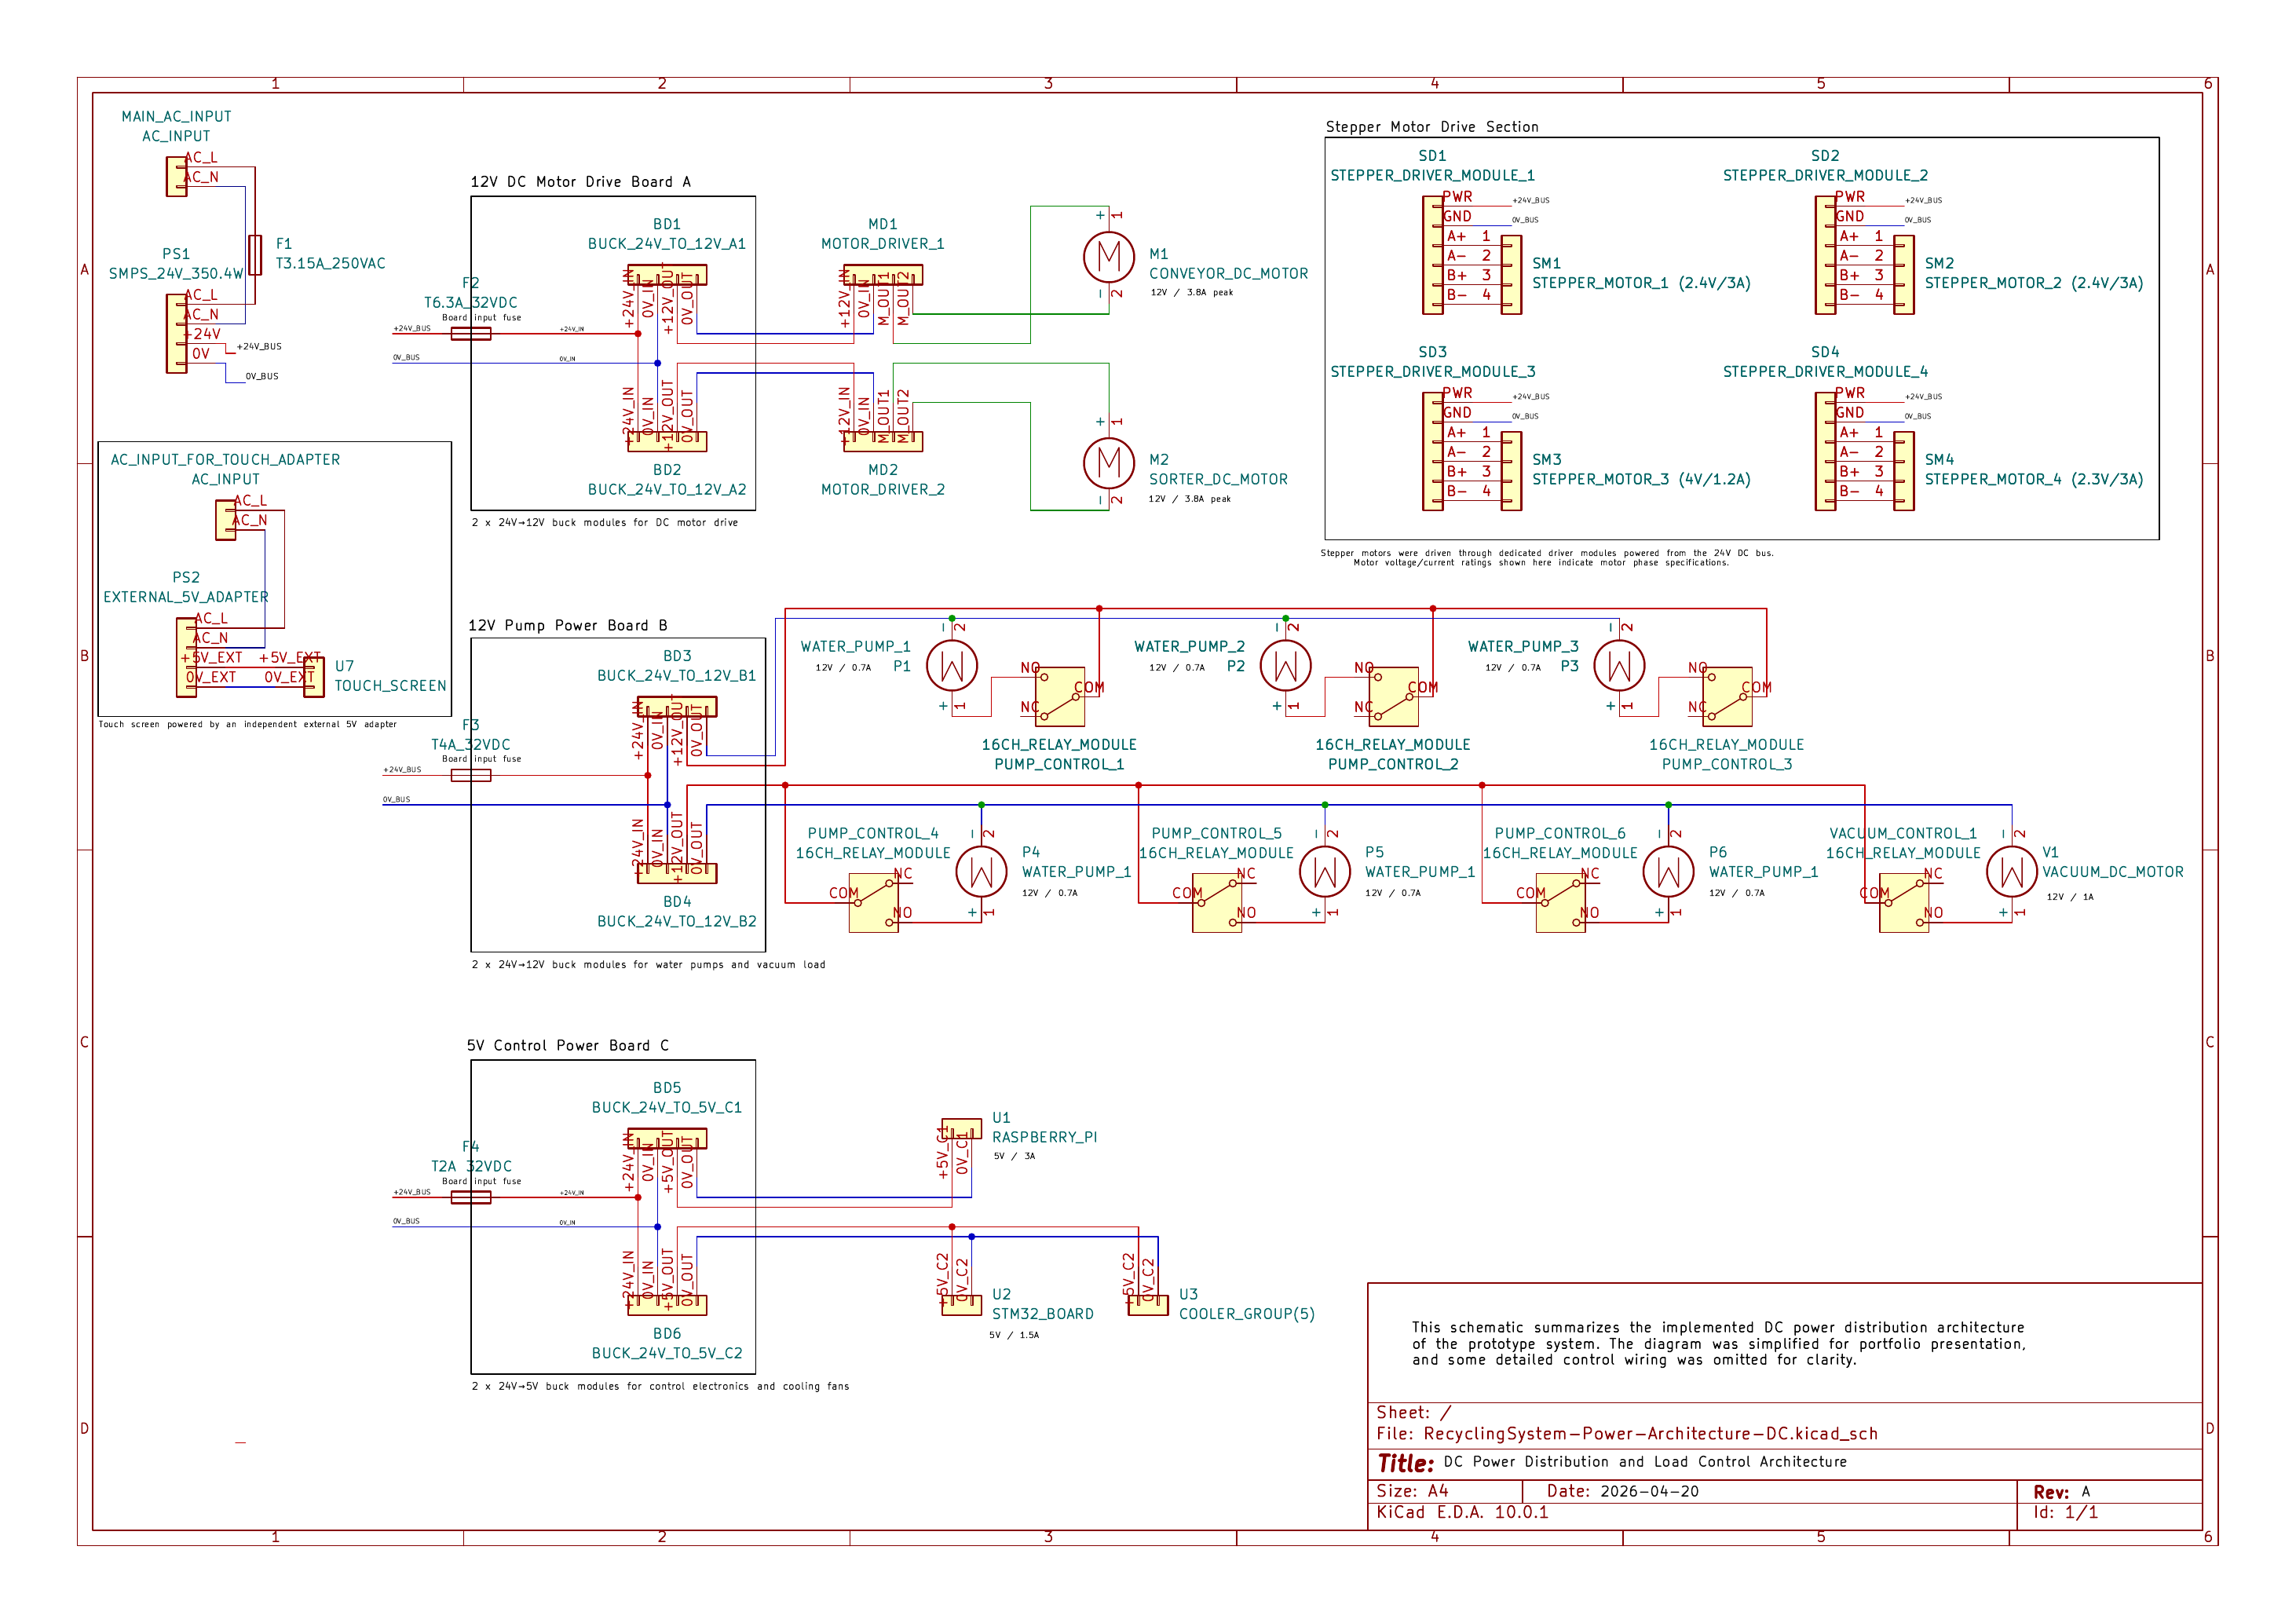
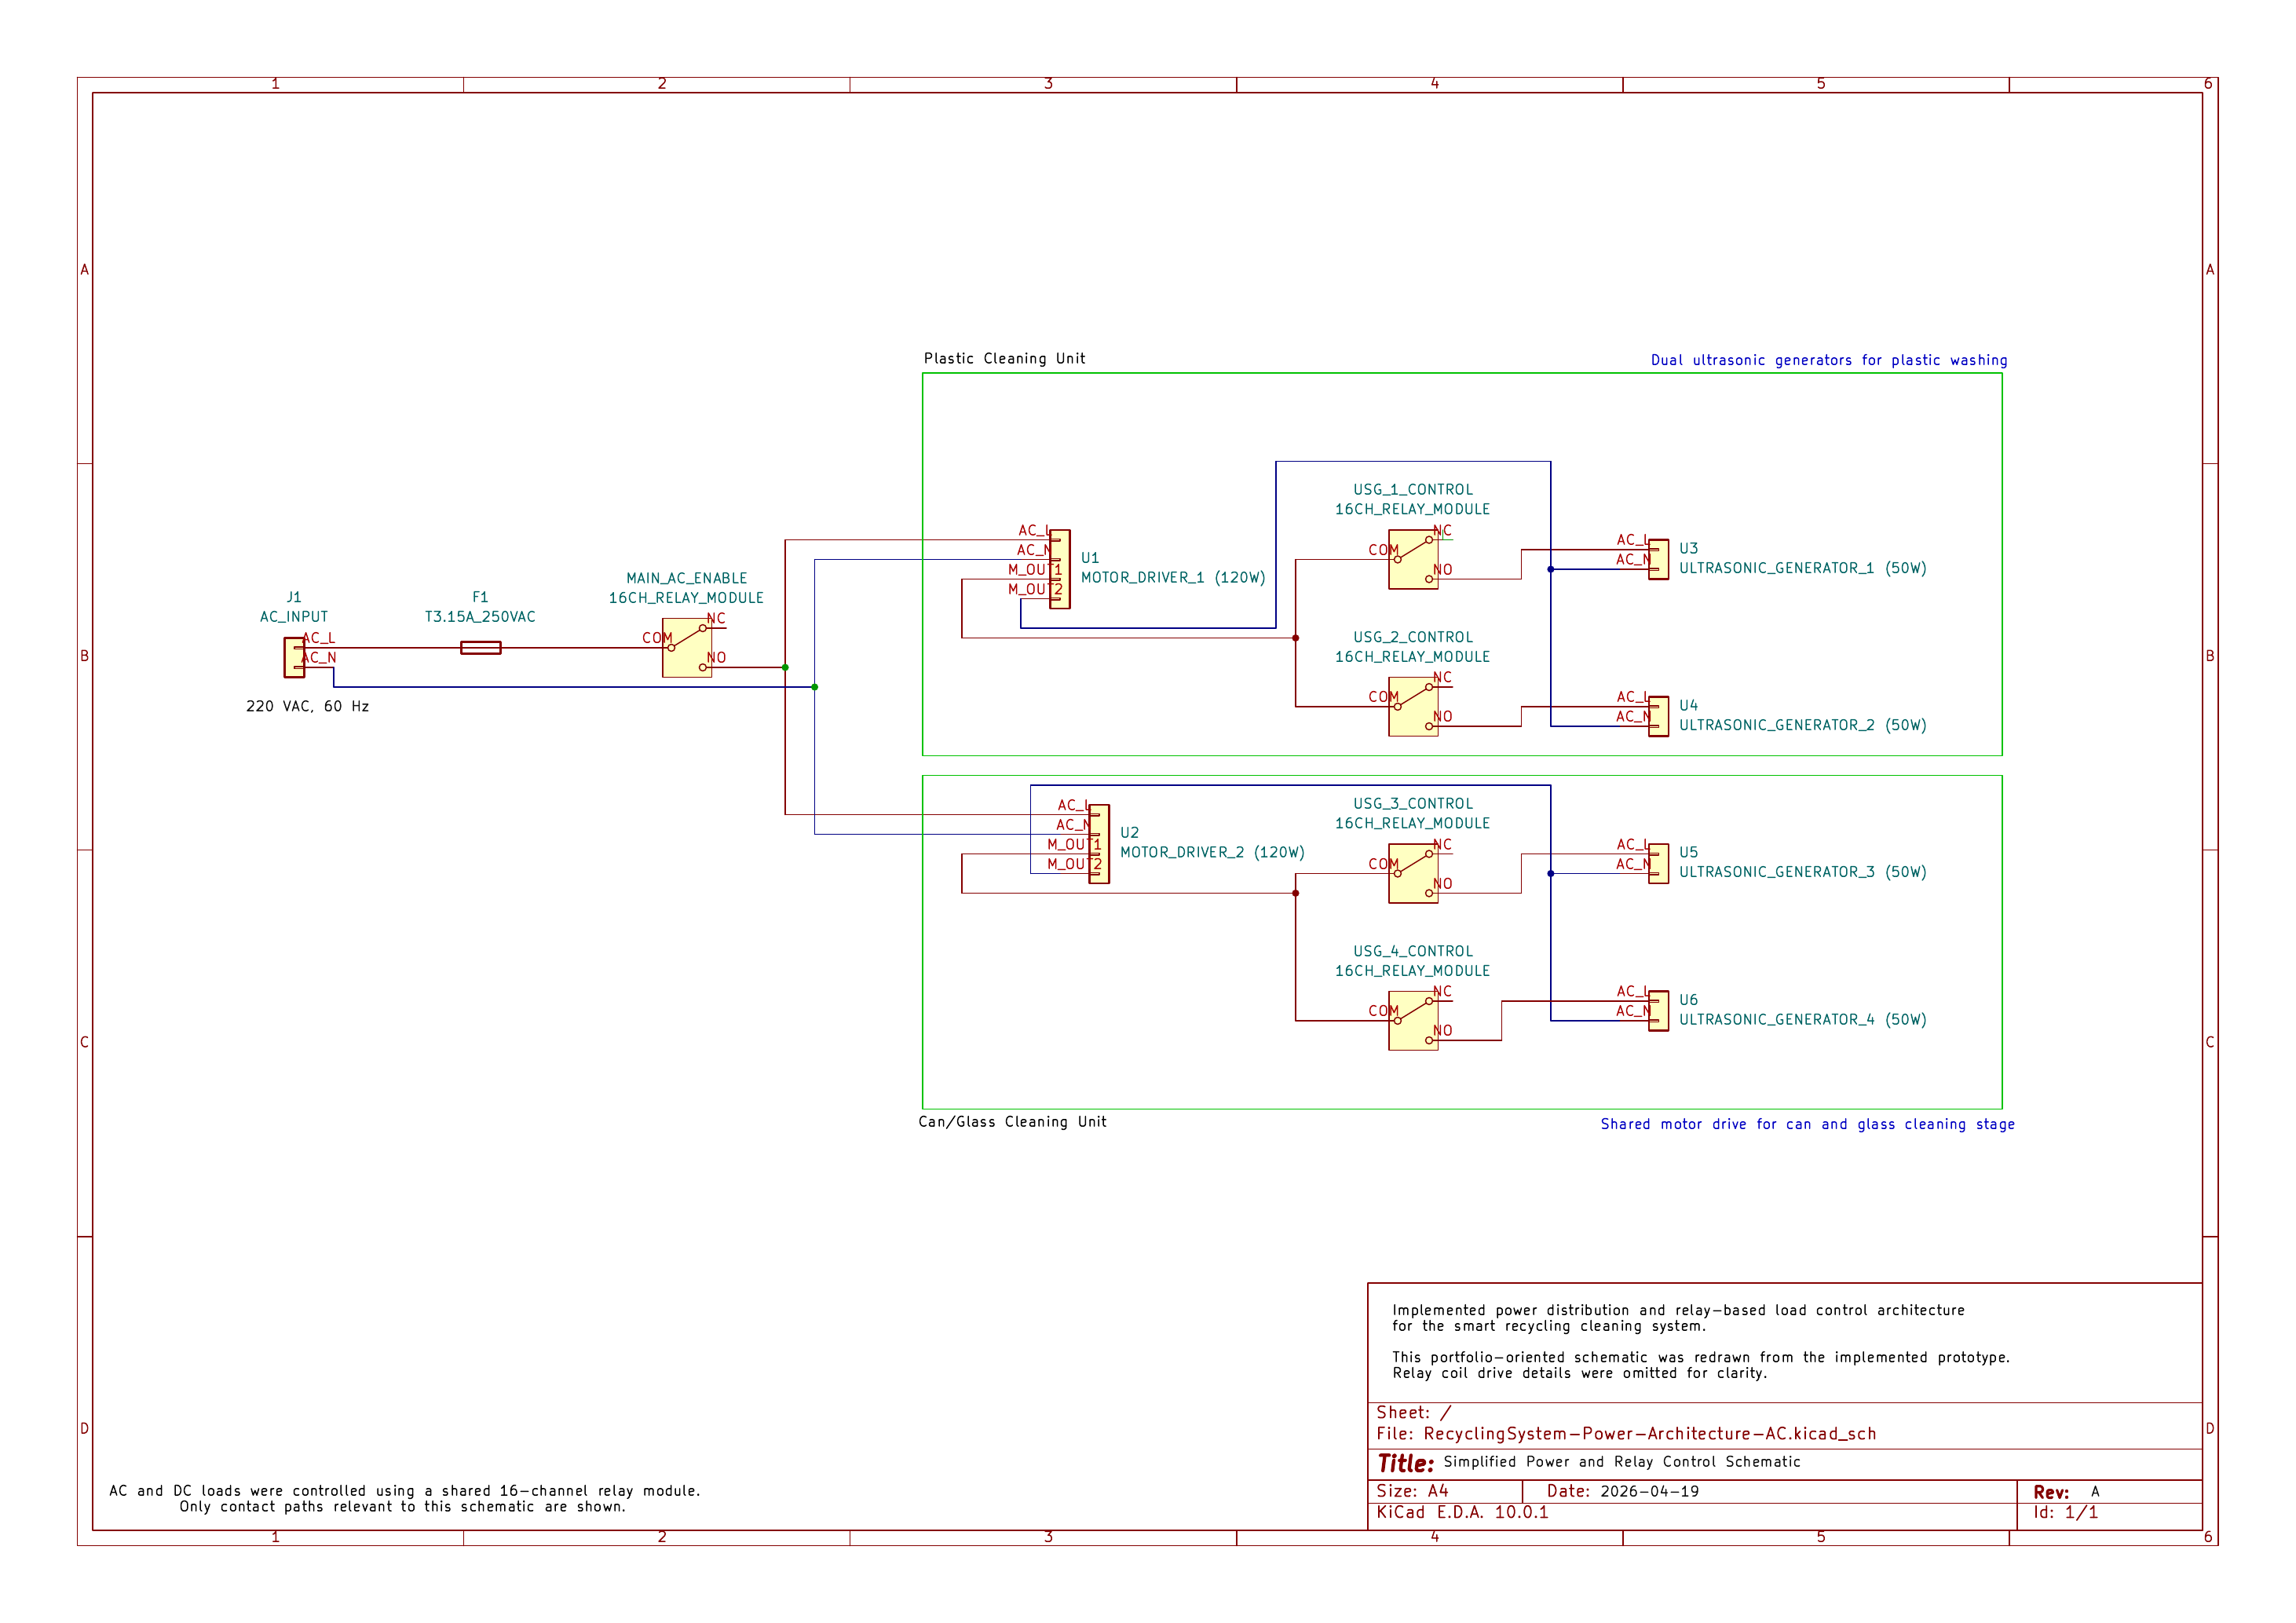
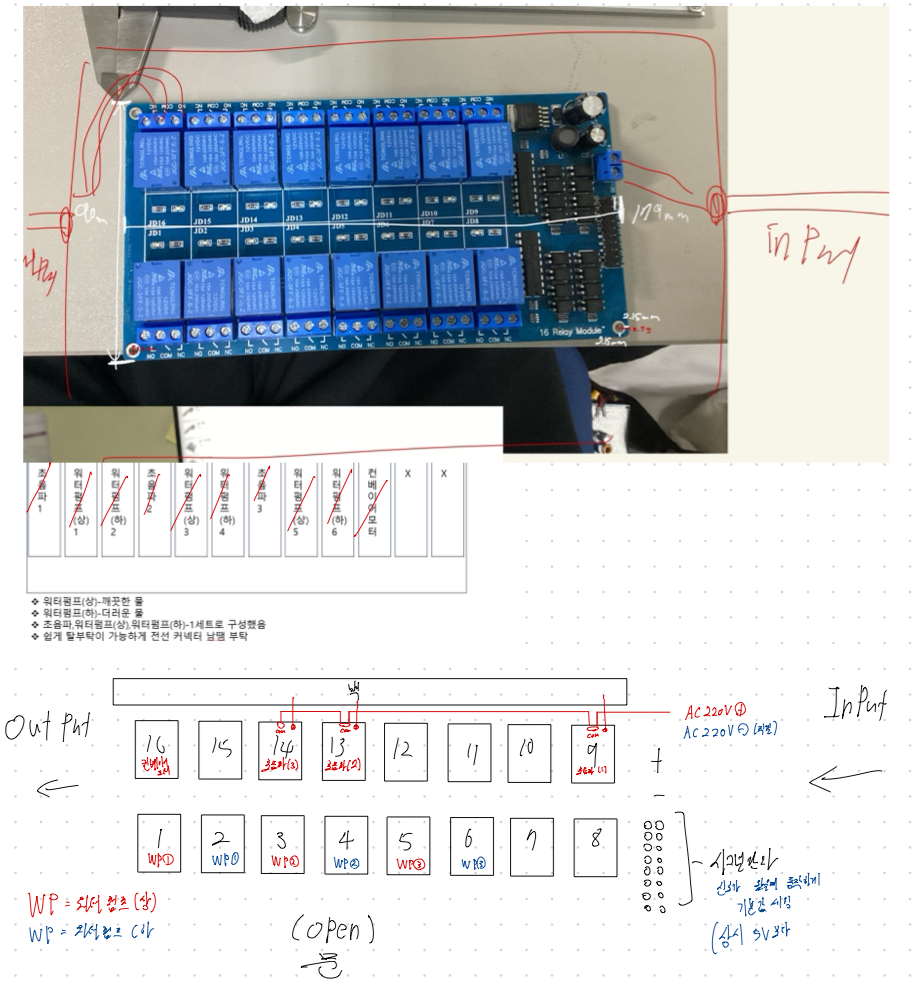
장비 작동 및 별도 모터 제어 실험
스마트 분리수거 장치 분류 동작 시연 (팀 프로젝트)
별도 STM32 모터 PID 실험 영상 2개 보기
STM32와 별도 엔코더 모터를 활용한 PID 제어 실험. 실제 컨베이어는 엔코더 신호 이상으로 PID 피드백 제어를 적용하지 못하고 PWM·시간 기반으로 운용.
STM32 모터 PID 제어 실험 (목표 100 rpm)
STM32 엔코더 모터 제어 실험
직접 수행한 전장·시스템 통합 작업
초음파 세척 장치 구성·시험
- 구성 진동자 50W 표기(플라스틱 2개, 캔 1개, 유리 1개)
드라이버 120W 표기 - 담당 부품 선정, 세척조·배선, 릴레이 구동 코드, 세척 시험
- 확인 커피 찌꺼기 제거 관찰 · 소음 및 고착 기름때 세척 한계
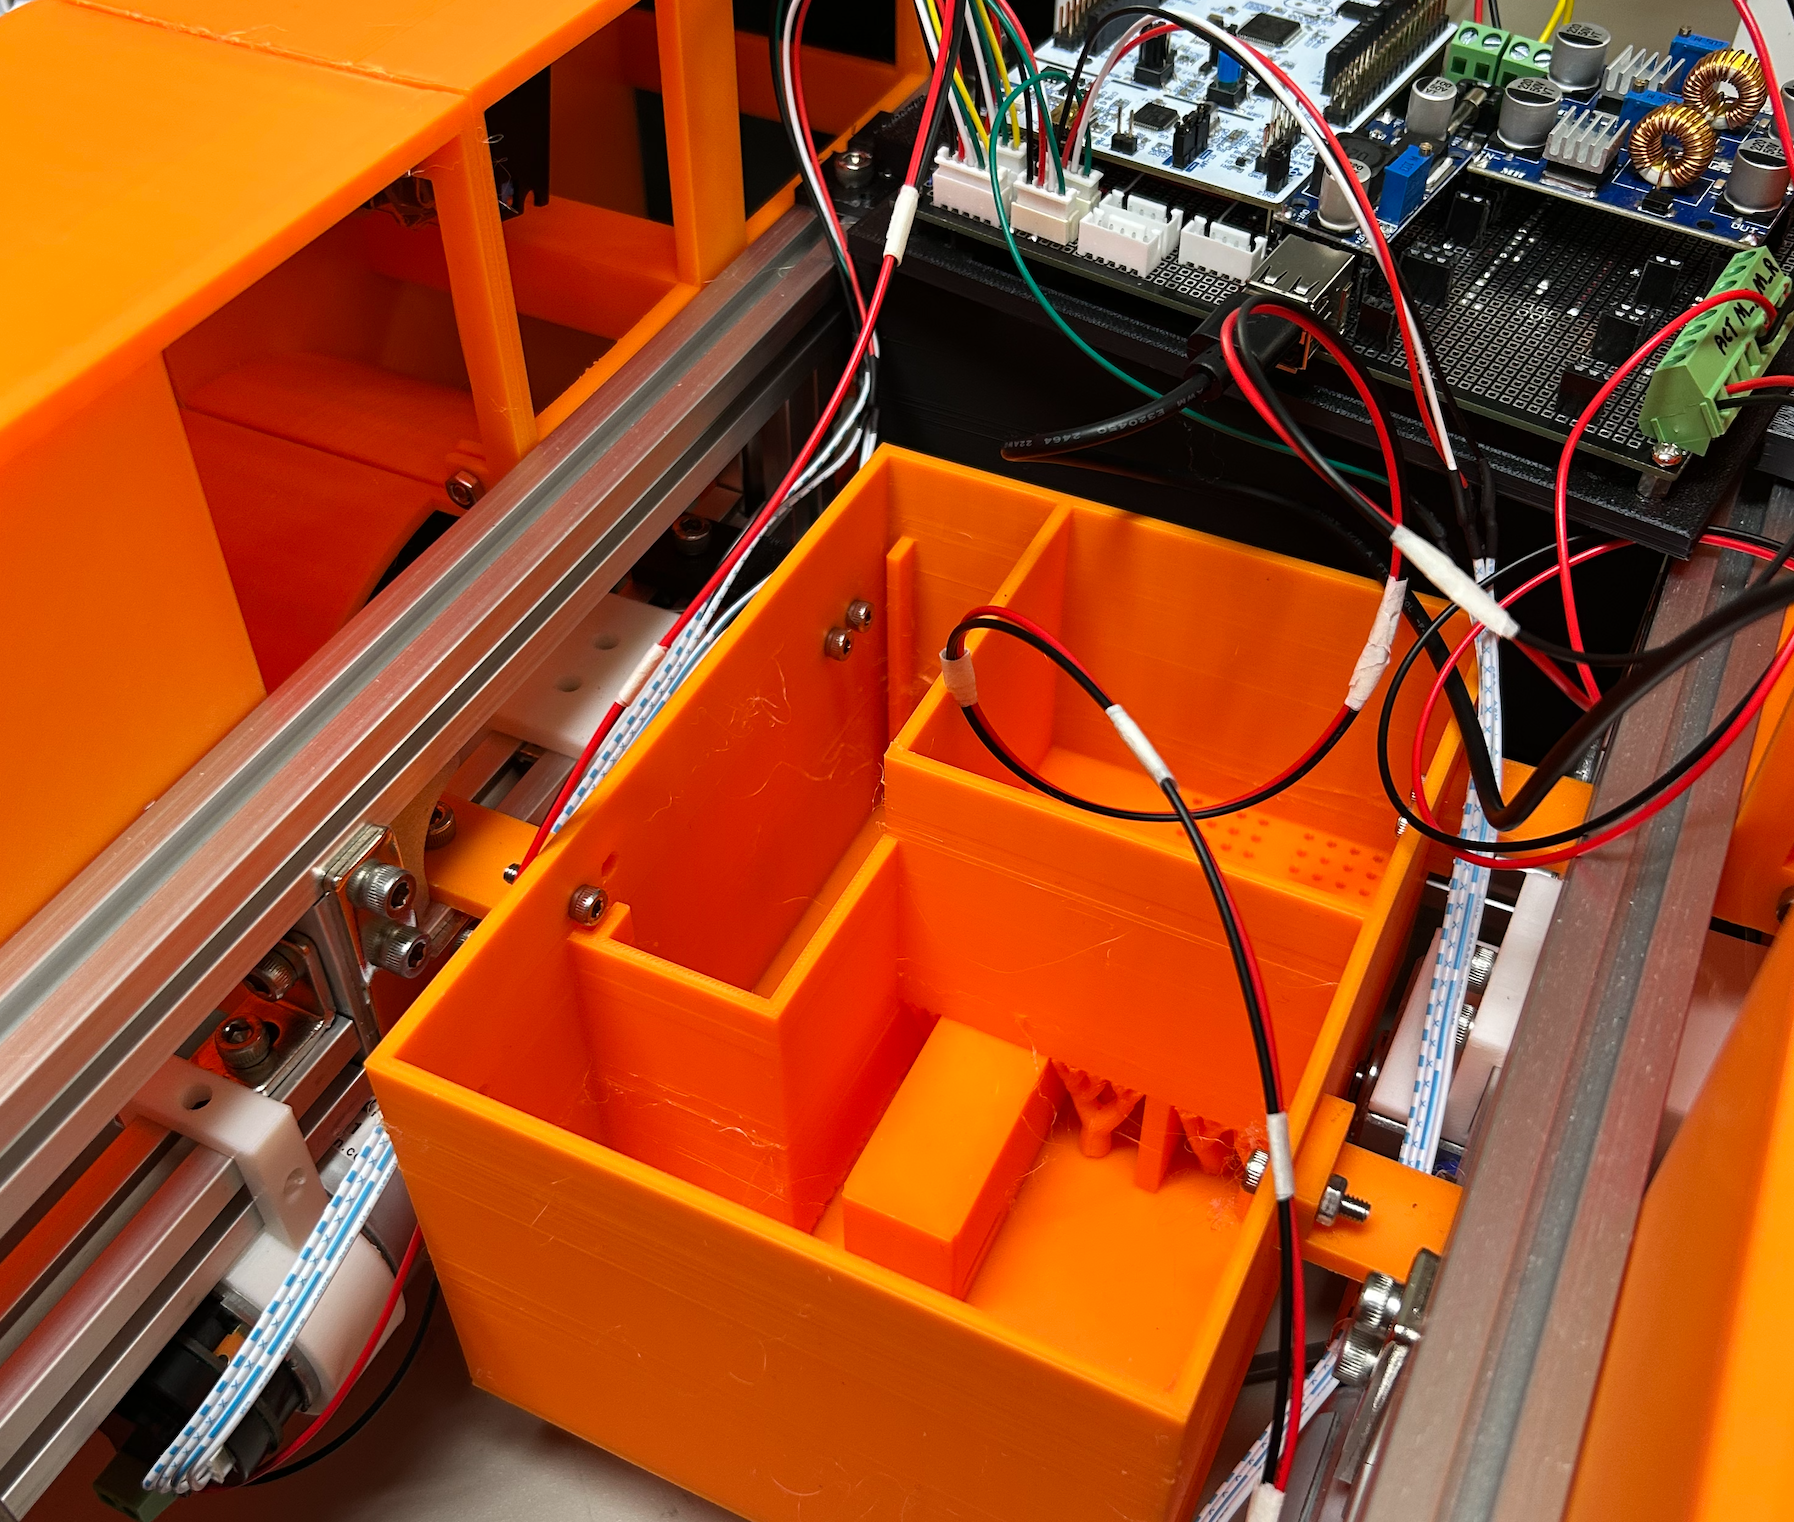
프레임·전장 박스 설계
- 프레임 컨베이어·쓰레기통 실측 기준 4040 프로파일 설계·조립
- 전장 박스 배선 점검용 서랍 구조, 냉각팬 포함 드라이버·릴레이 박스
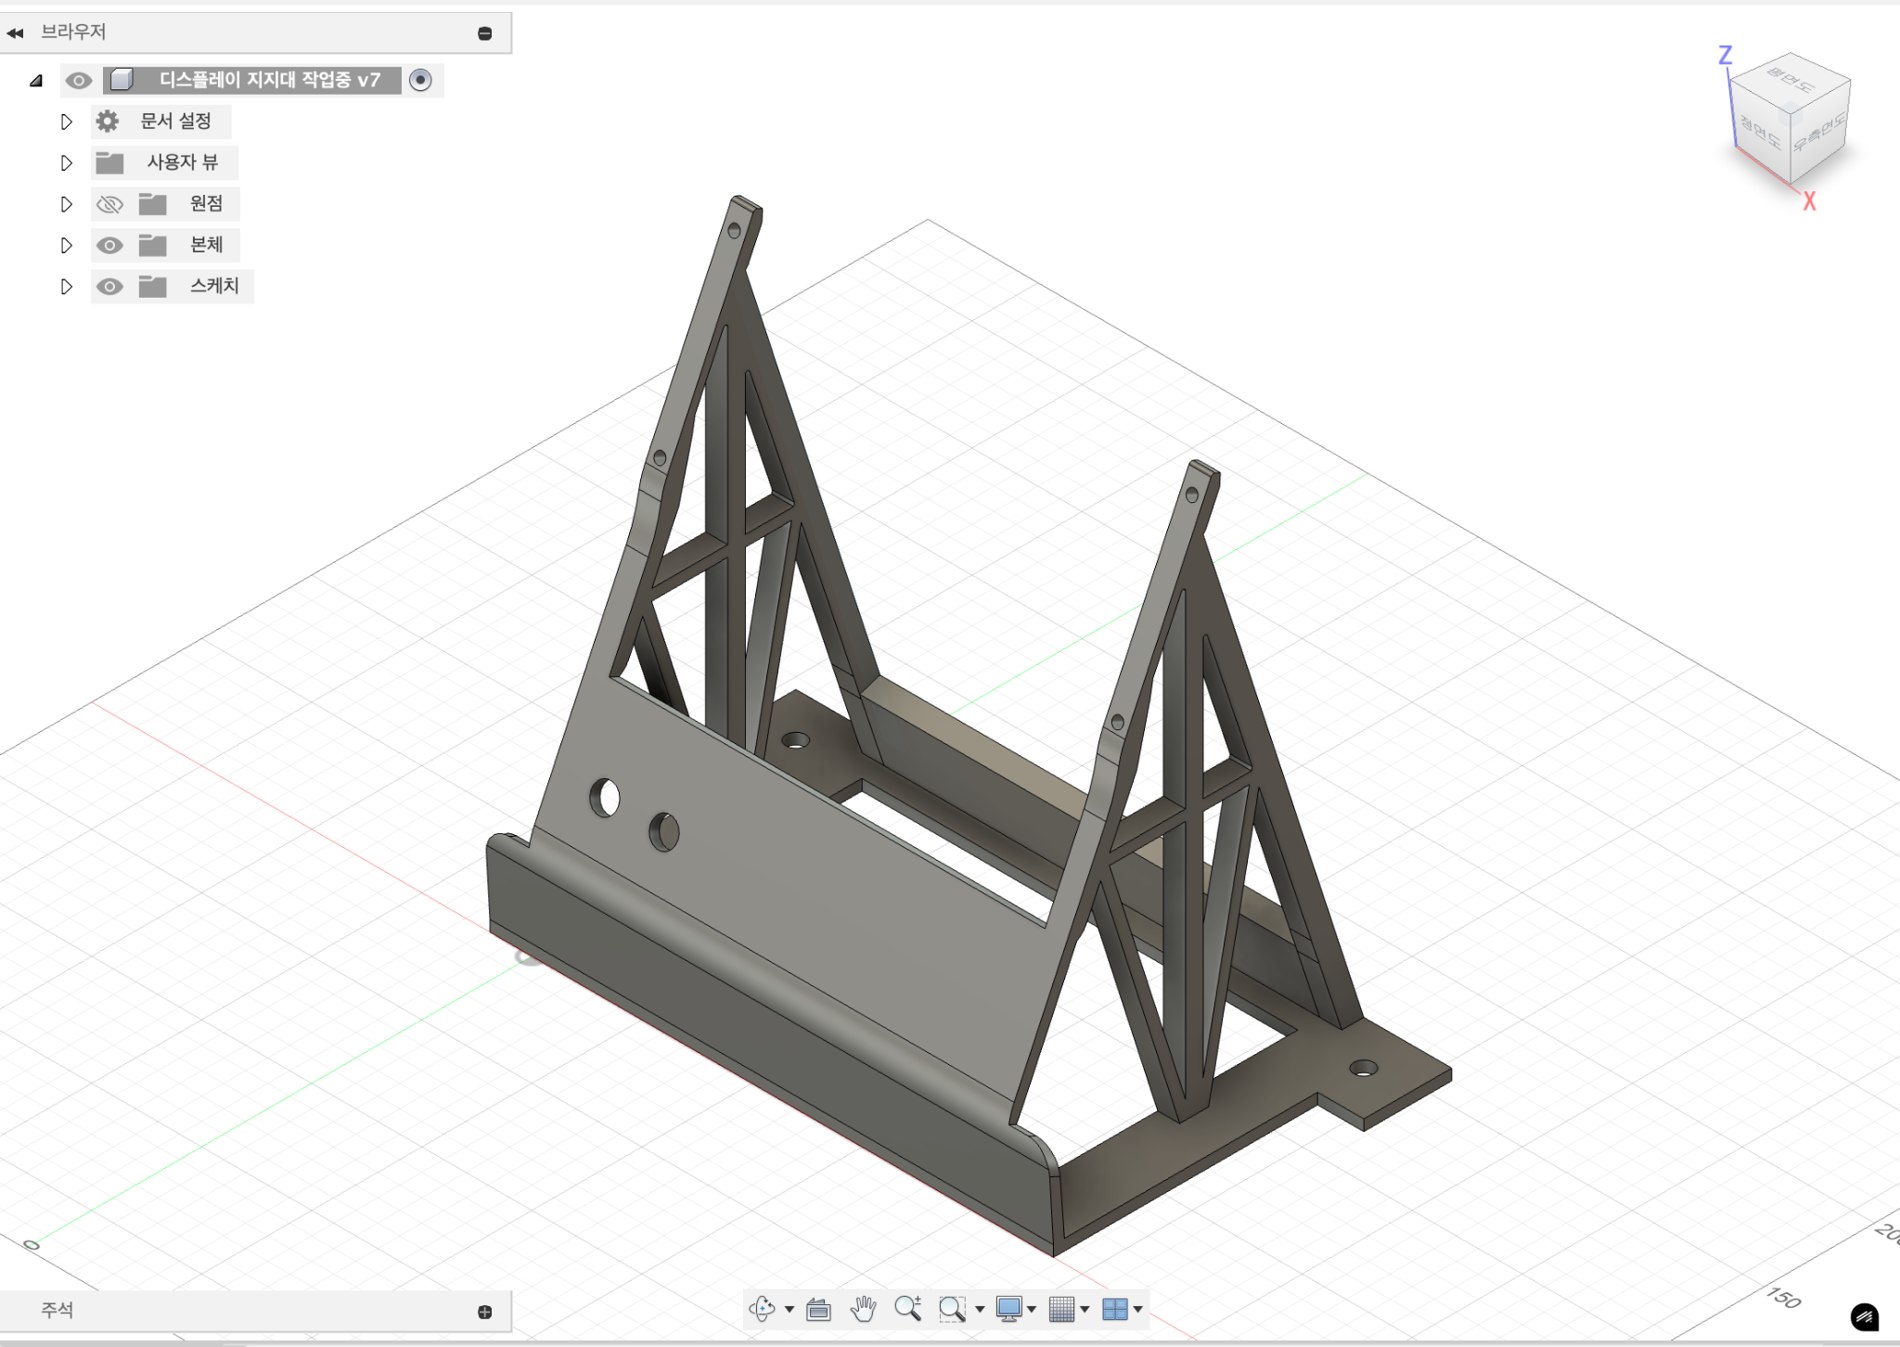
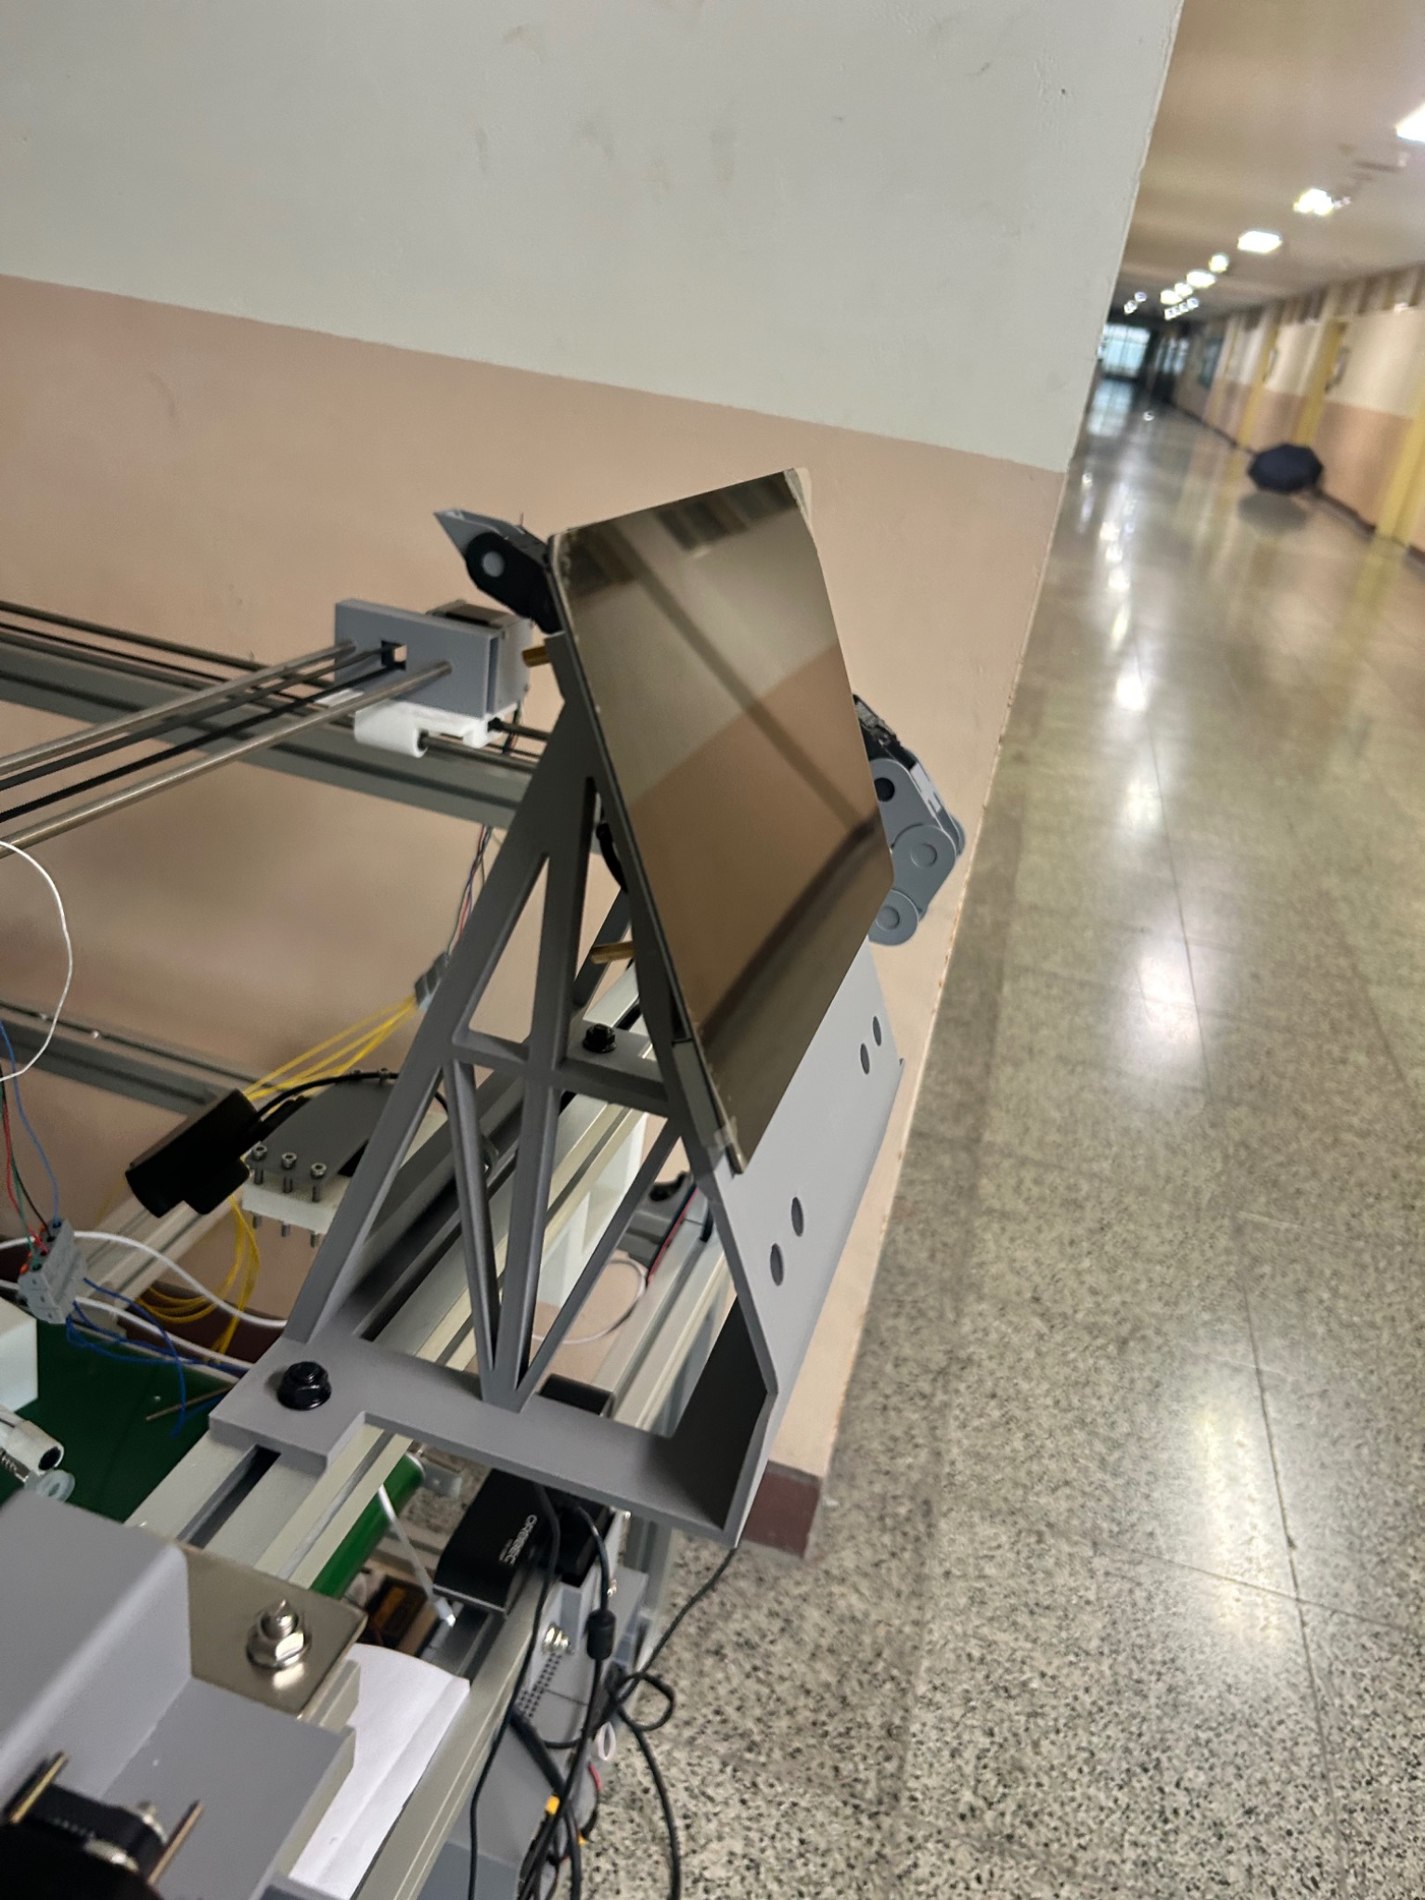
- 현장 수정 직교좌표 로봇 실물 치수에 맞춰 설치 브라켓 추가
담당 구분 · 영상 인식, 직교좌표 로봇 제어, STM32–Raspberry Pi 통신: 팀원
사용자 UI 및 장비 모니터링
Touch UI and Equipment Monitoring
Raspberry Pi setup and AI-assisted Python touch UI; live sensor gauges; operational stop/restart in administrator mode. STM32–Raspberry Pi communication was implemented by a teammate.
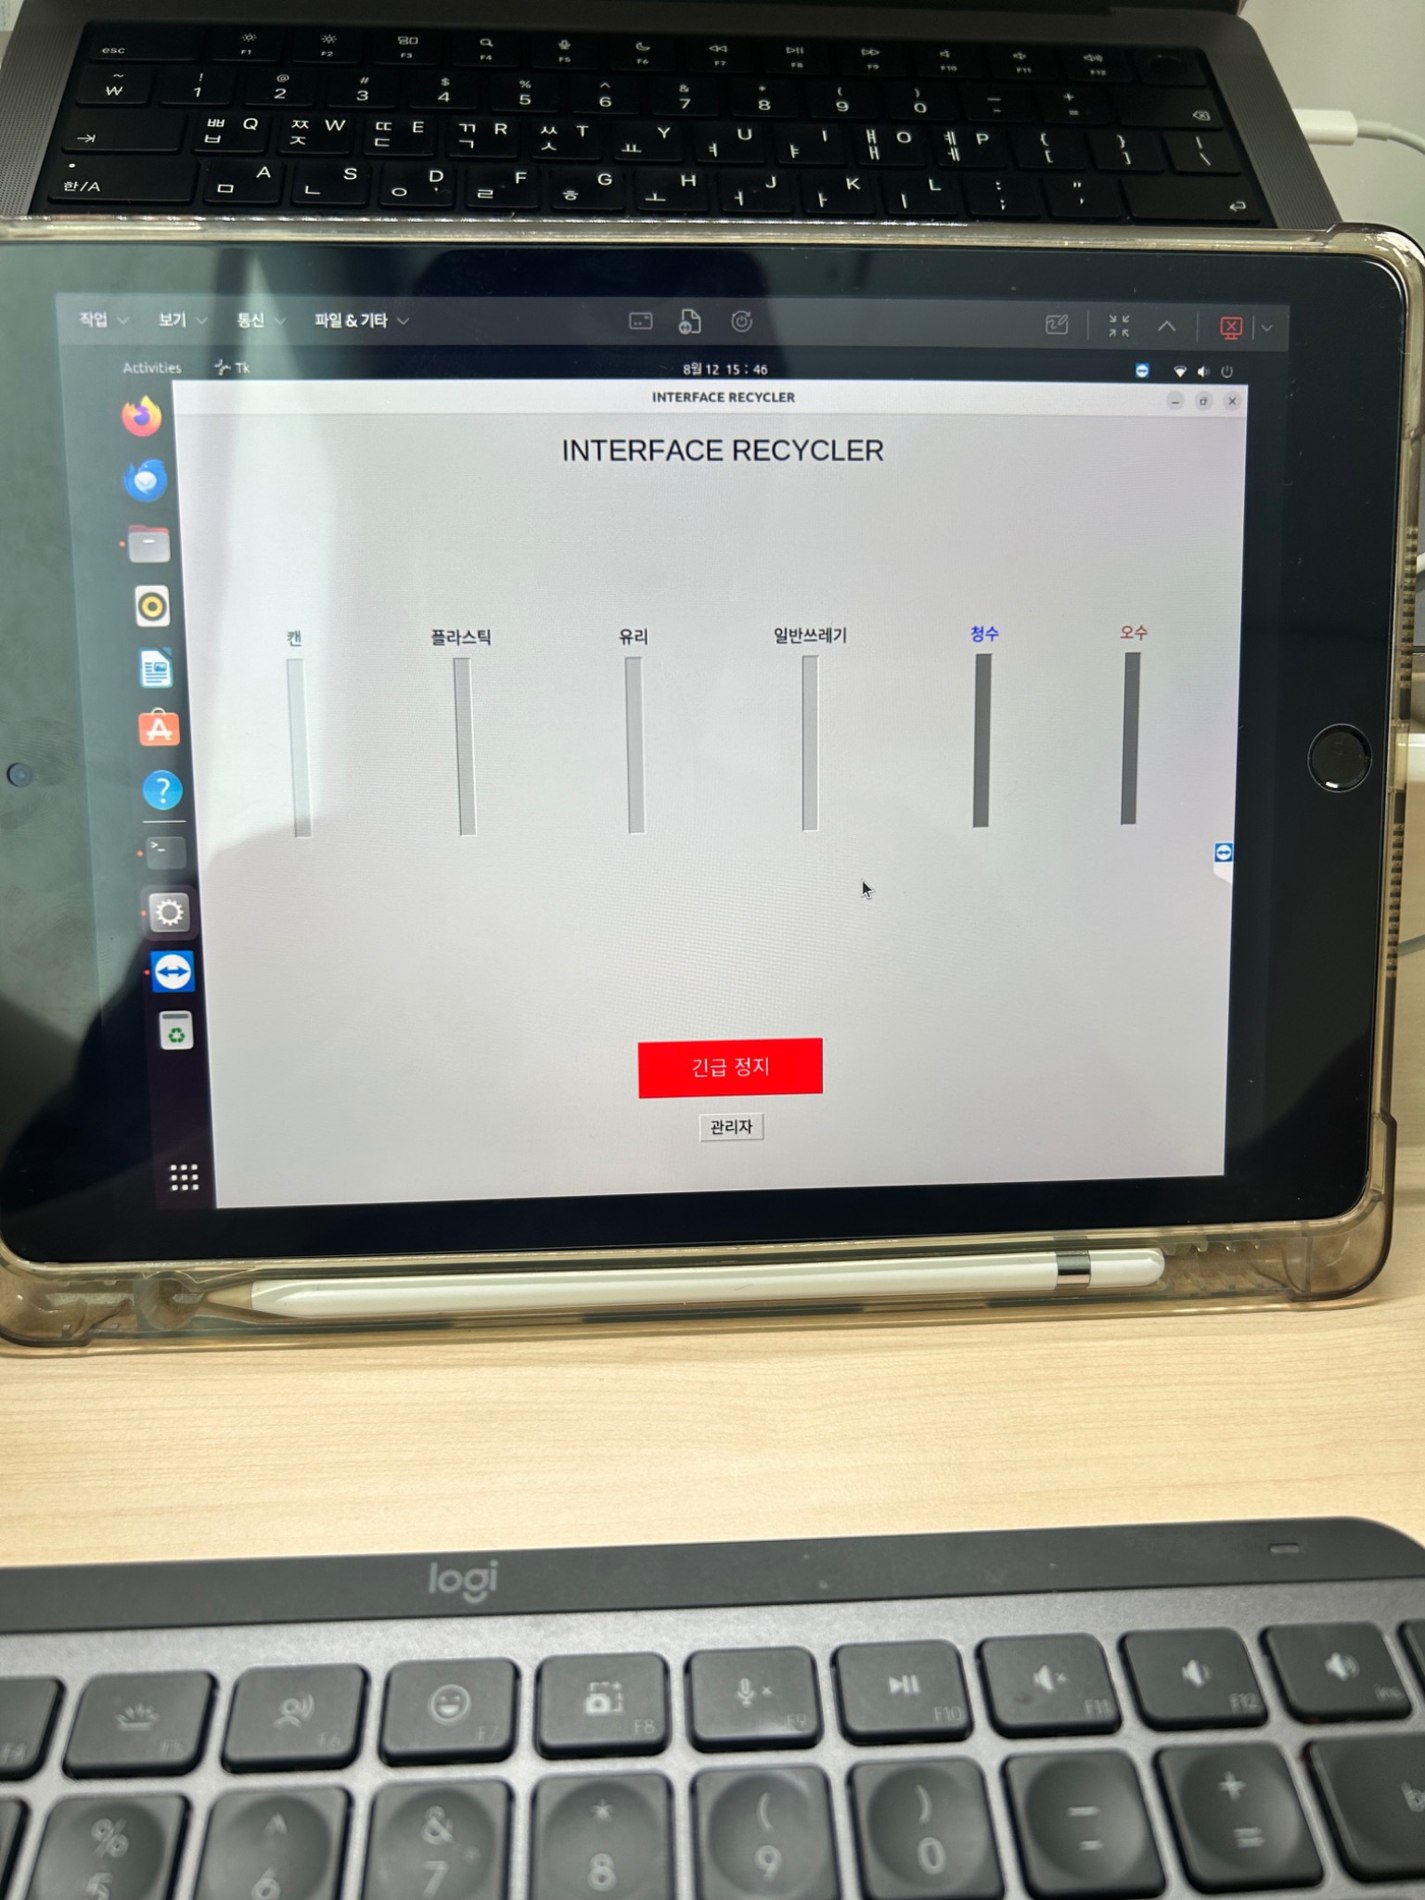
상태 게이지 및 관리자 UI 동작 시험 (약 27초)
기술 요소
Technical Elements
- STM32, C, Fusion 360, KiCad
- 로봇 시스템 구조 설계 및 제어부 통합
- Timer 기반 PWM 모터 구동
- 별도 엔코더 모터 속도 측정 및 PID 튜닝
- Relay 기반 AC 220V 부하 분리 제어
- DC 24V → 12V/5V 전력 분배 설계
- 부하 특성 검토 및 전원 분배 경로 변경
- STM32, C, Fusion 360, KiCad
- Robot system architecture design and controller integration
- Timer-based PWM motor drive
- Encoder-based speed measurement and PID tuning on a separate motor
- Relay-based isolation control for AC 220V loads
- DC 24V → 12V/5V power distribution design
- Load review and power distribution reconfiguration
성과
Achievements
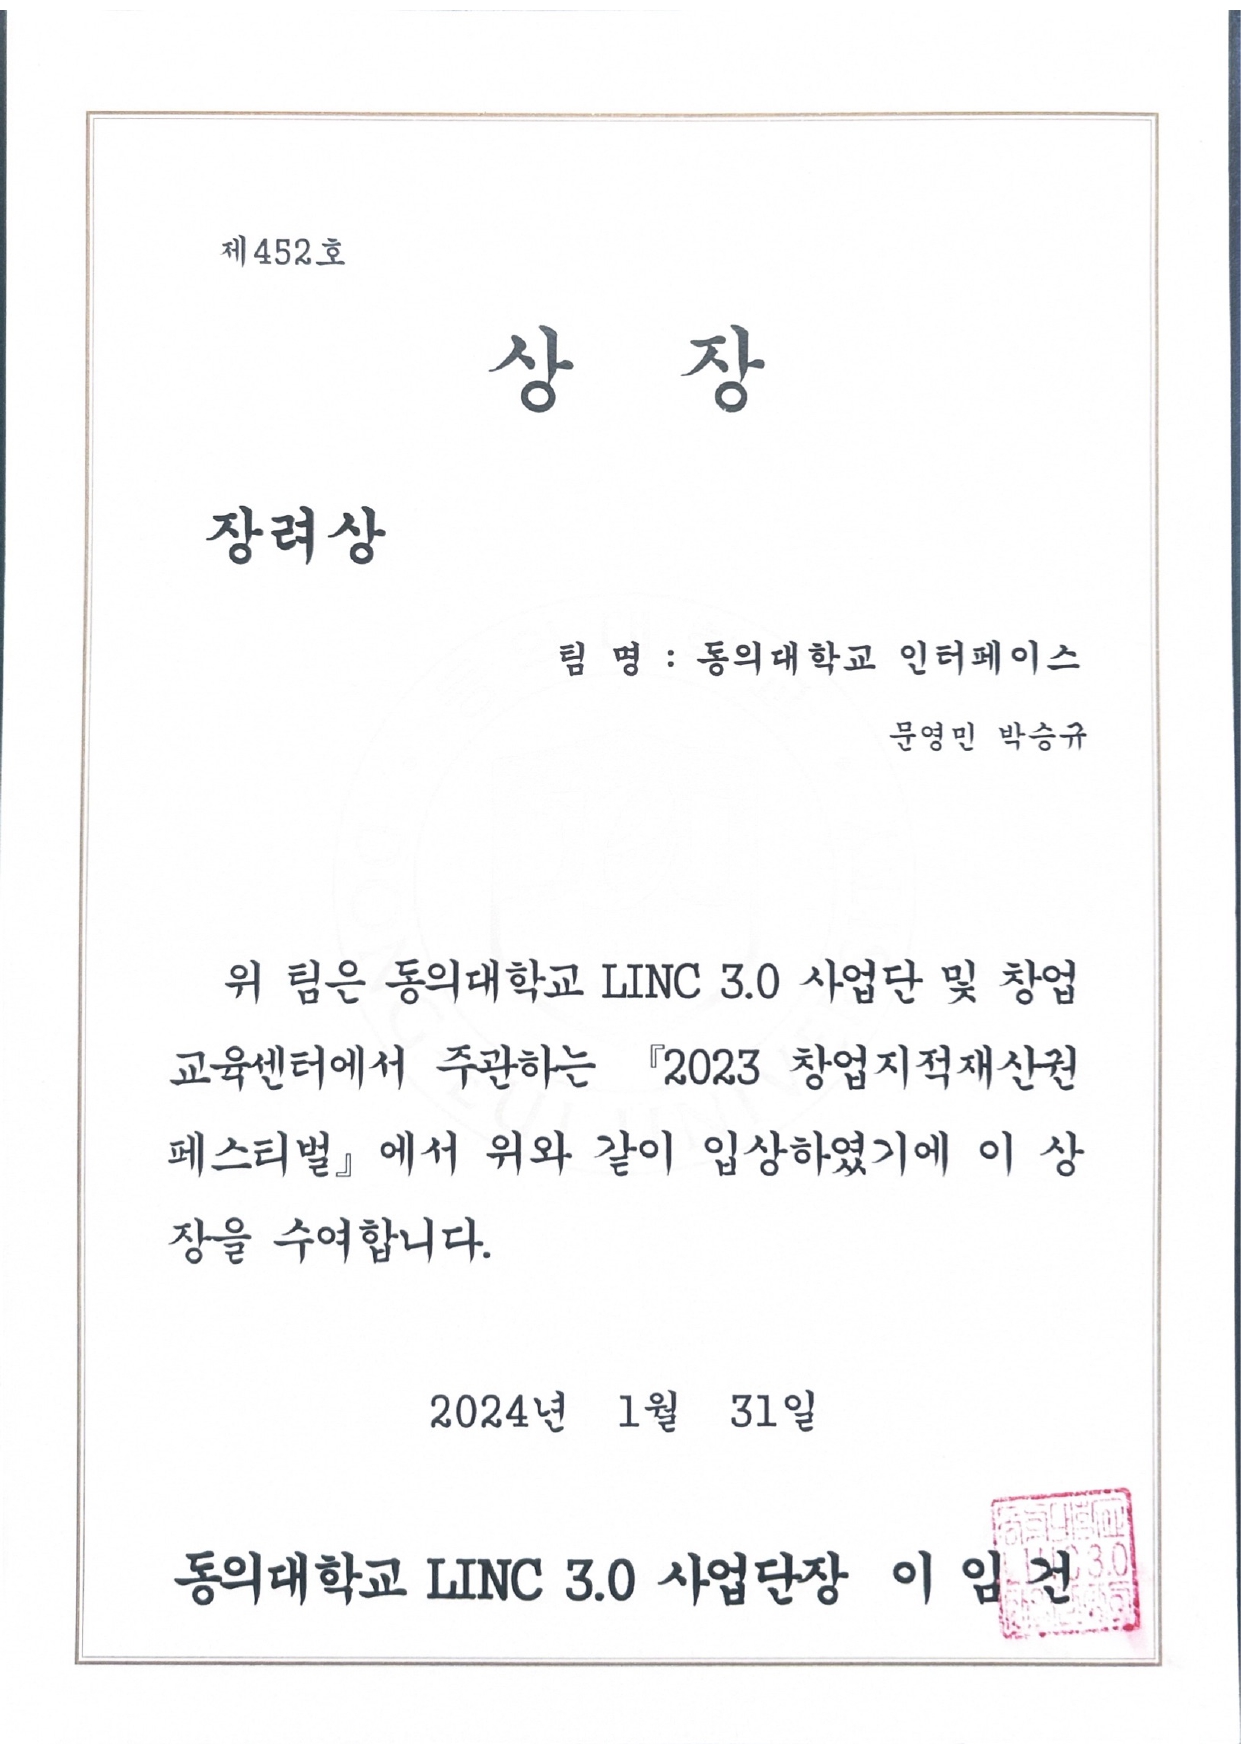
- [교내] 창업지적재산권 페스티벌 장려상
- 특허 출원
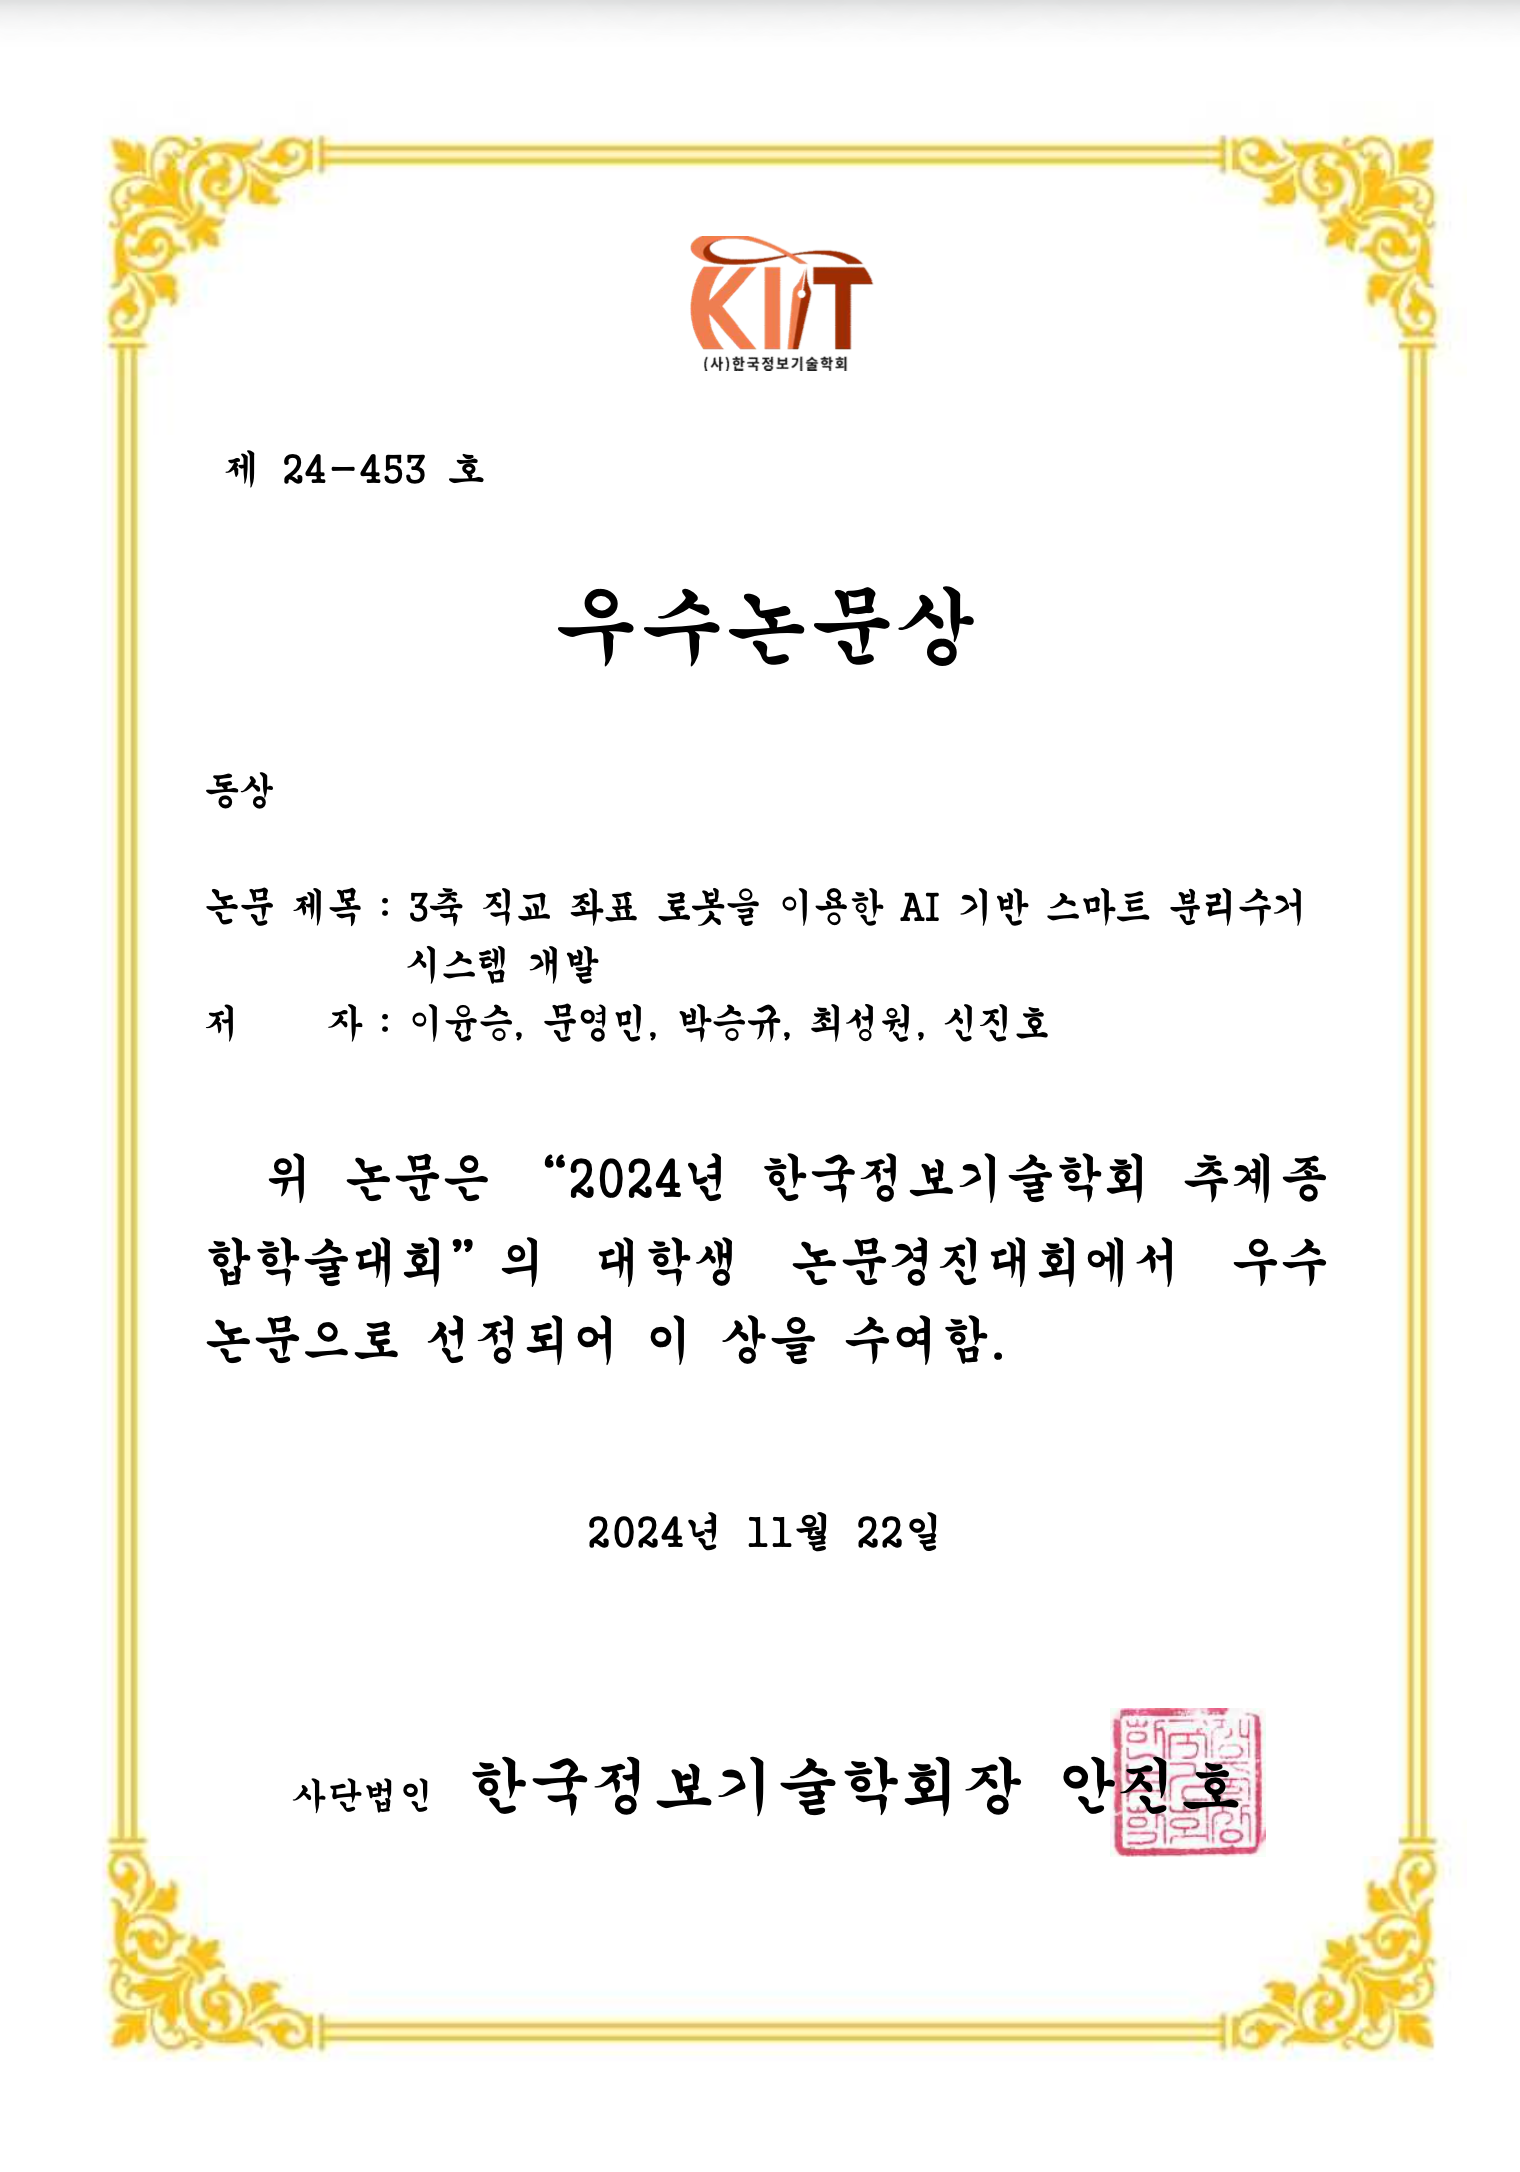
- [교외] 한국정보기술학회 추계종합학술대회 동상
- [교내] 캡스톤디자인 경진대회 특별상
- [Campus] Entrepreneurship/IP Festival — Encouragement Award
- Patent application filed (co-inventor; not registered)
- [External] KIIT Fall Conference — Bronze Award
- [Campus] Capstone Design Competition — Special Award